YouTube Streamer



hu-po

Robotics Researcher
Founder
 ▶ Watch original
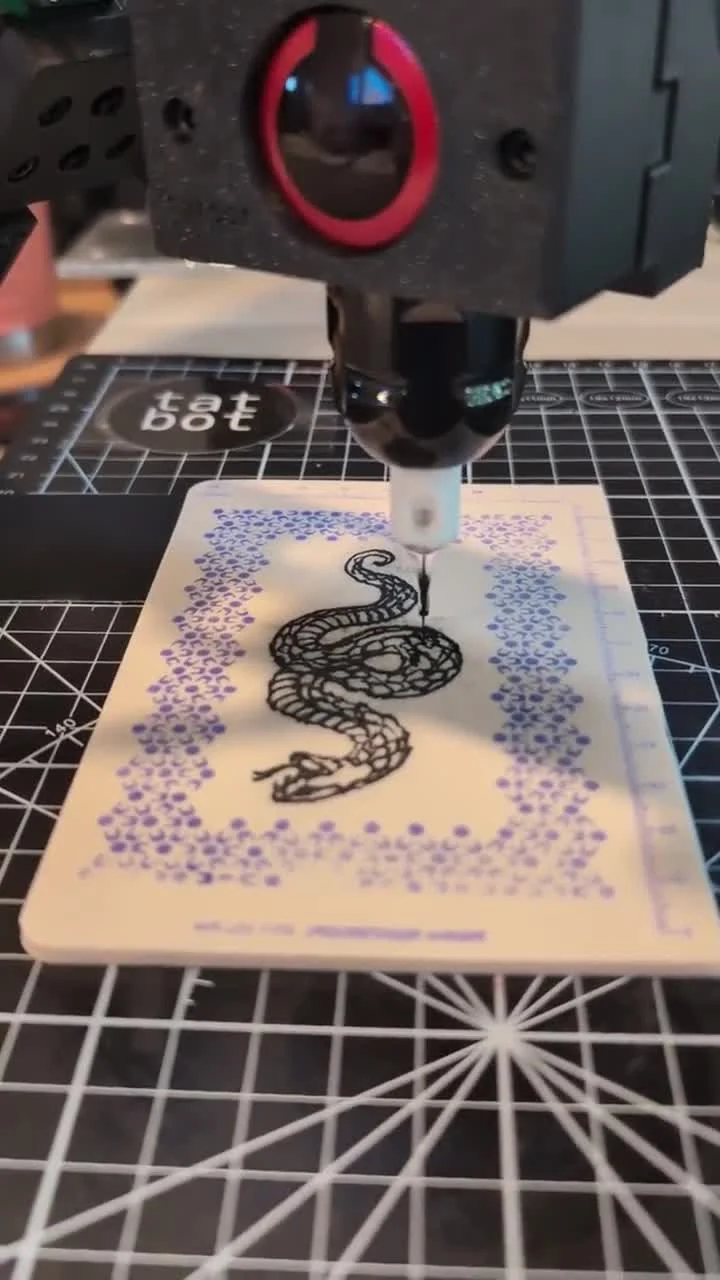
silicone skin
 ▶ Watch original
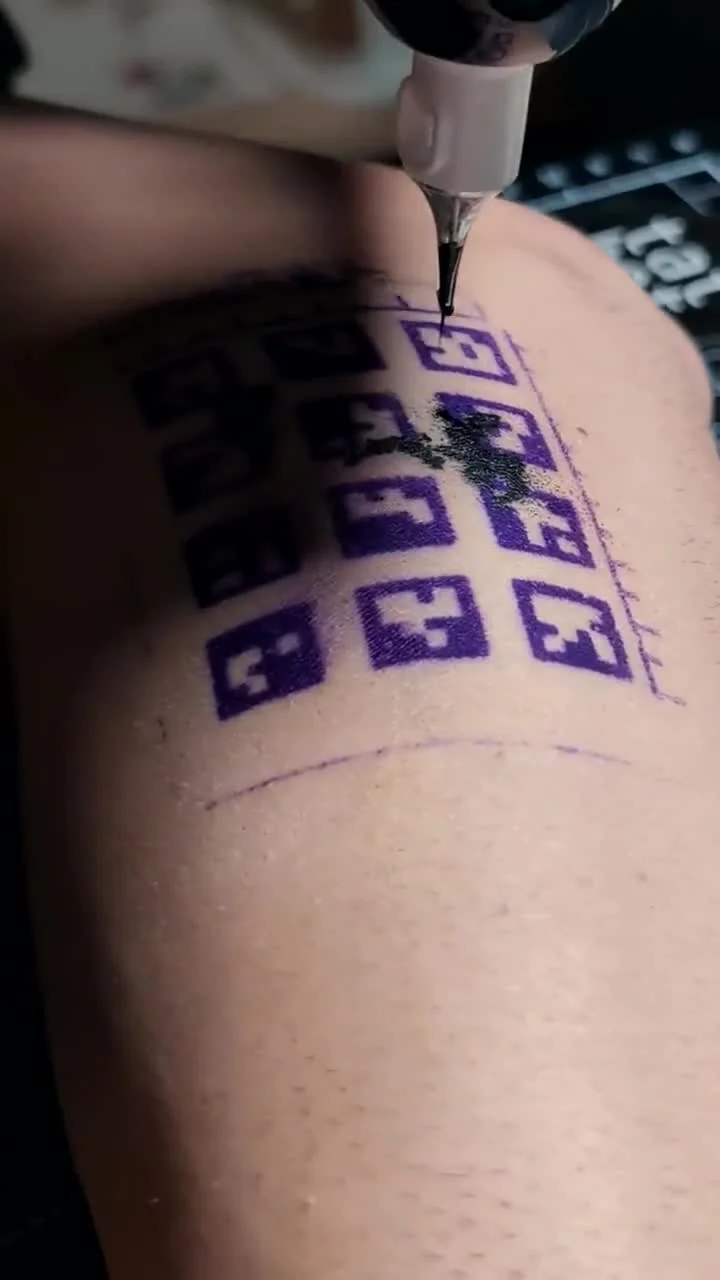
forearm tattoo
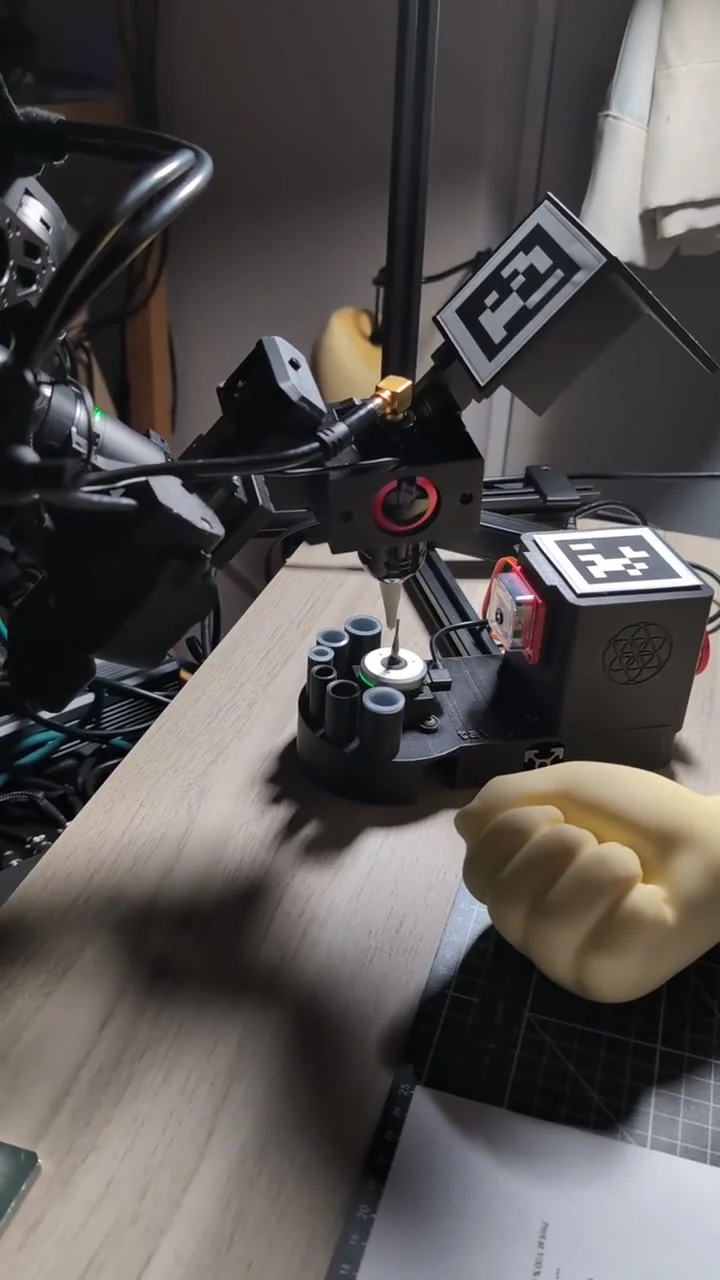 ▶ Watch original
palette calibration
Recorded research footage · early human self-test does not establish readiness for use on other people.
Tatbot Hardware
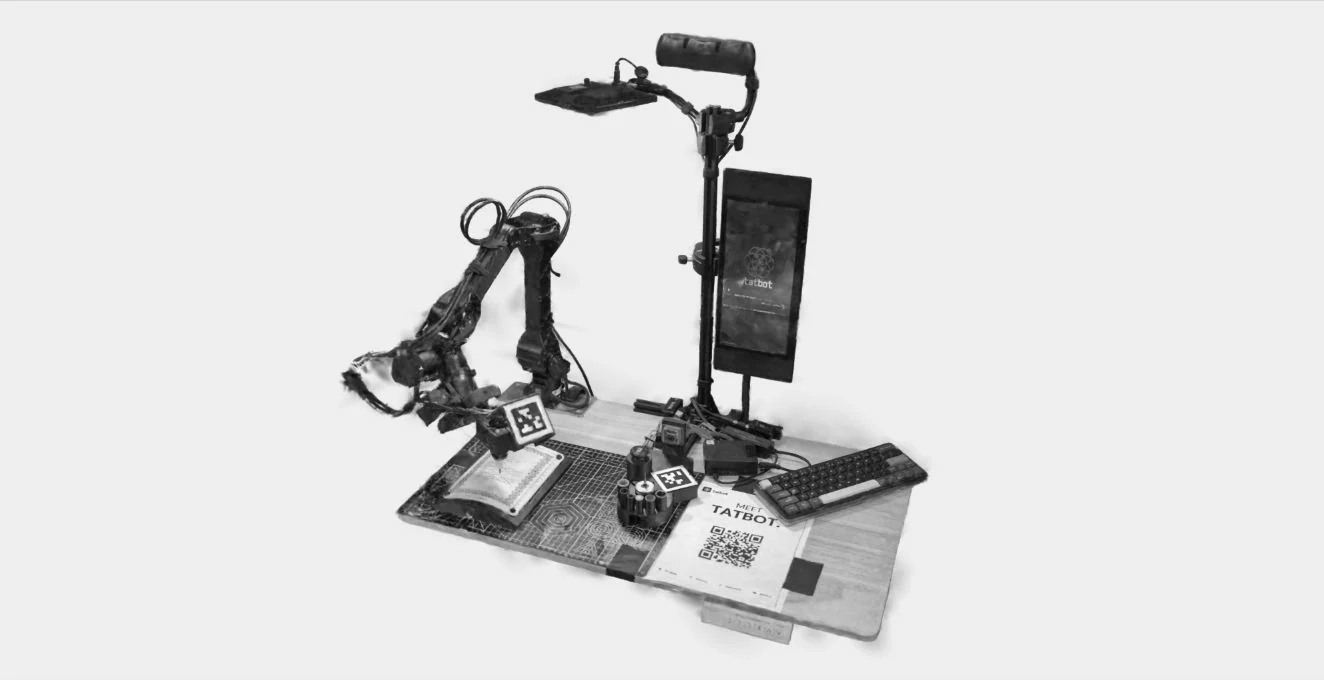
2xD405
Depth: 30fps | 1280x720
RGB: 30fps | 1280x720
RGB: 30fps | 1280x720
Tattoo pen
Trossen WXAI arm
6 DoF | 1.5kg payload
Acc./Rep.: 1mm
Acc./Rep.: 1mm
Palette
PETG-CF | 6 inkcaps
D555
Depth: 30fps | 640x360
RGB: 30fps | 1280x720
RGB: 30fps | 1280x720
Touch display
RPi camera
60fps | 1920x1080
Raspberry Pi
8GB | 4-core A76
Touch probe
Thor
128GB unified
14-core Arm CPU
Blackwell GPU
2070 TFLOPS (FP4)
14-core Arm CPU
Blackwell GPU
2070 TFLOPS (FP4)
Spark
128GB unified
20-core Arm CPU
Blackwell GPU
1000 TFLOPS (FP4)
20-core Arm CPU
Blackwell GPU
1000 TFLOPS (FP4)
Claude Code
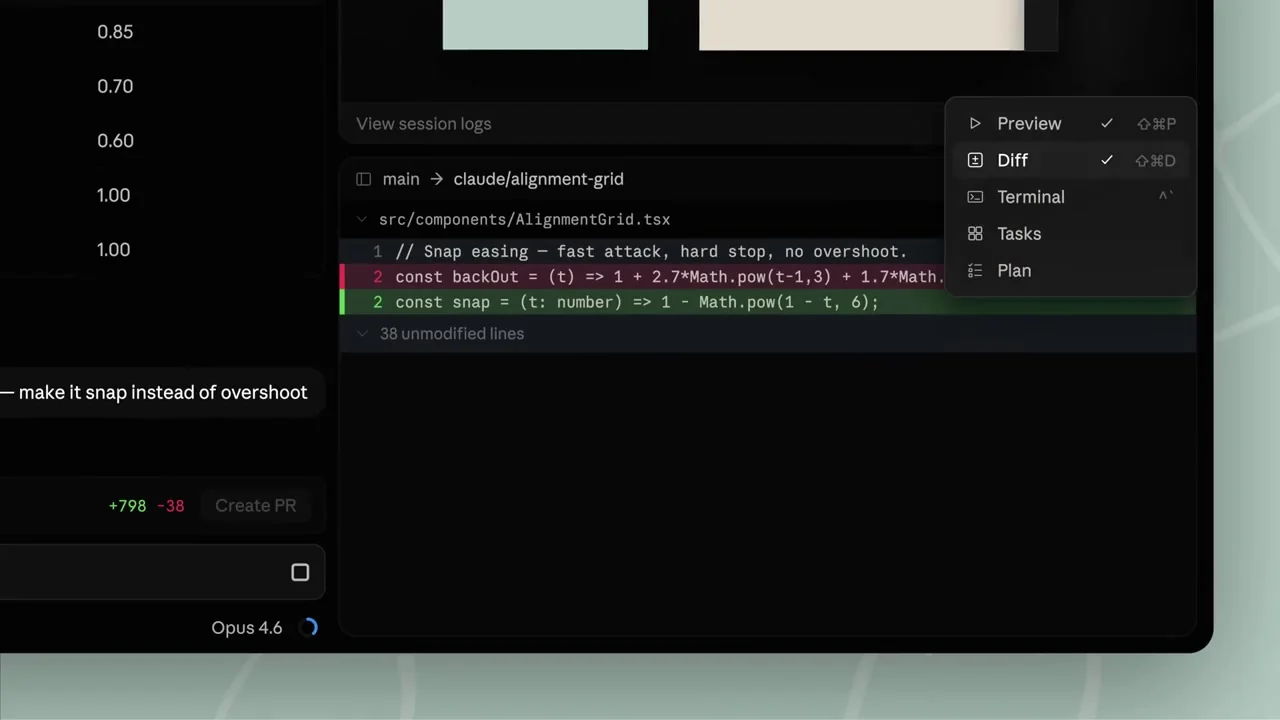 ▶ Watch original
Replit Agent
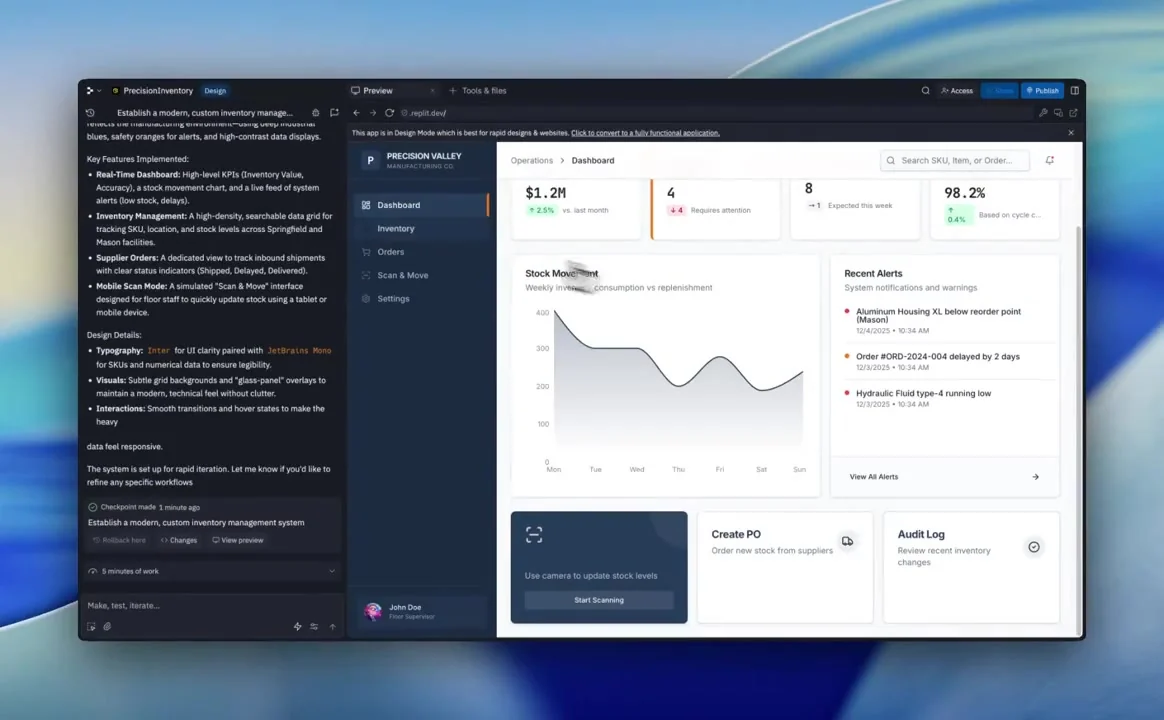 ▶ Watch original
MeshFormer
Direct 3D asset generation
Text or image
RGB + normals
Textured mesh
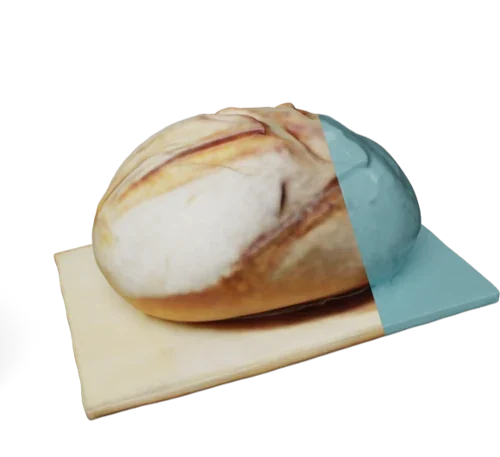
Sourdough bread
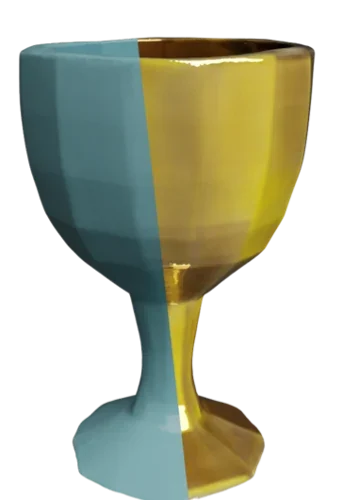
Golden goblet
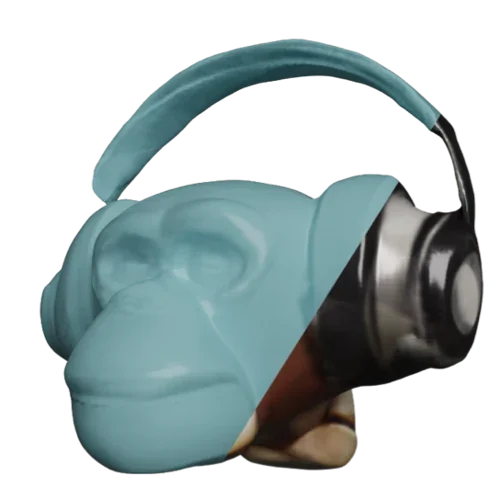
Chimpanzee with
headphones
headphones
Claude + Blender MCP
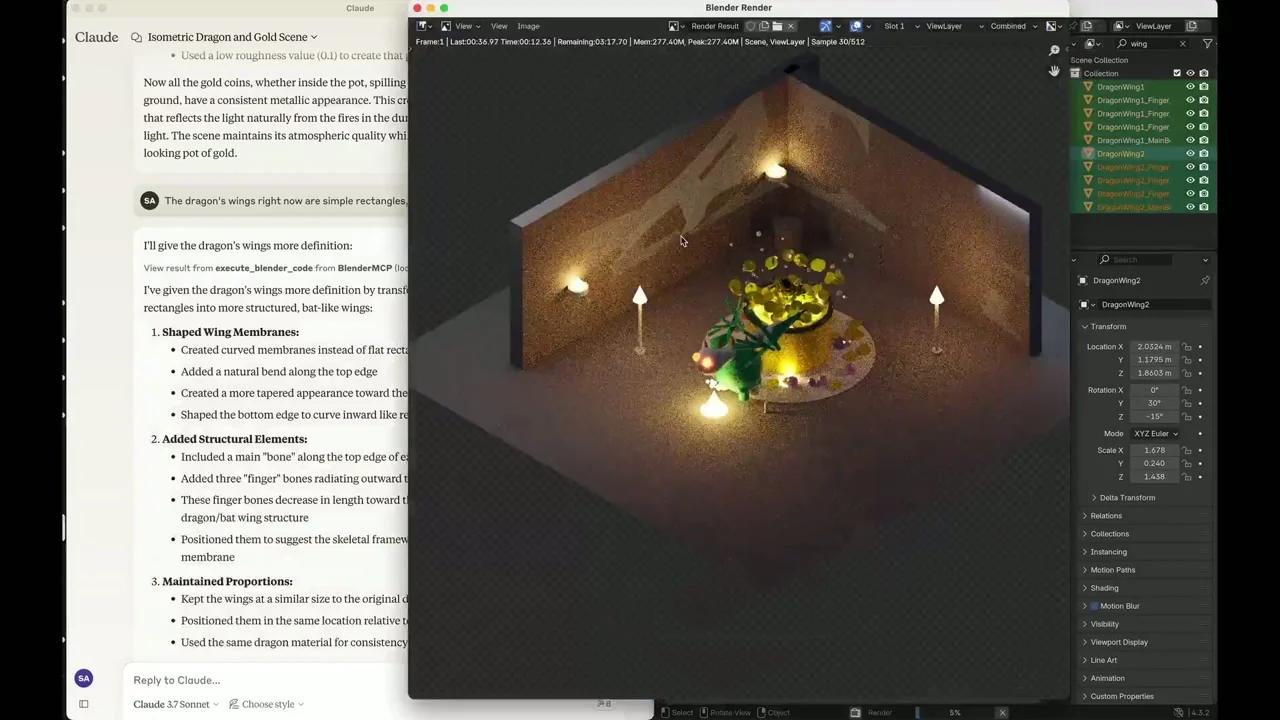 ▶ Watch original
Tatbot Palette 🎨
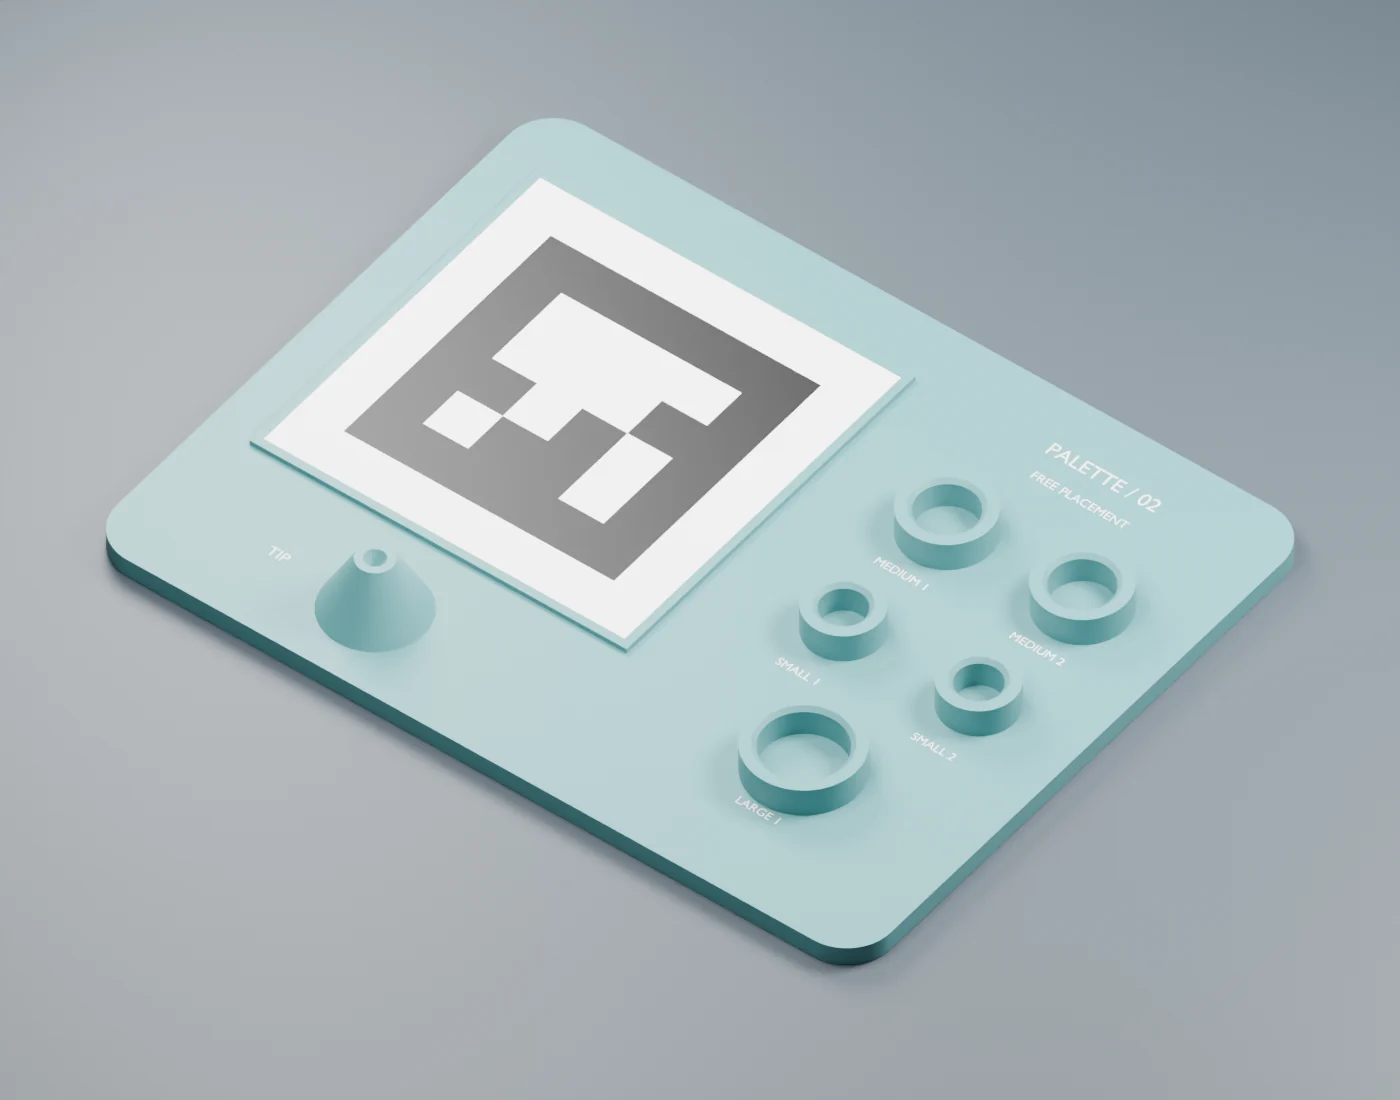
v1
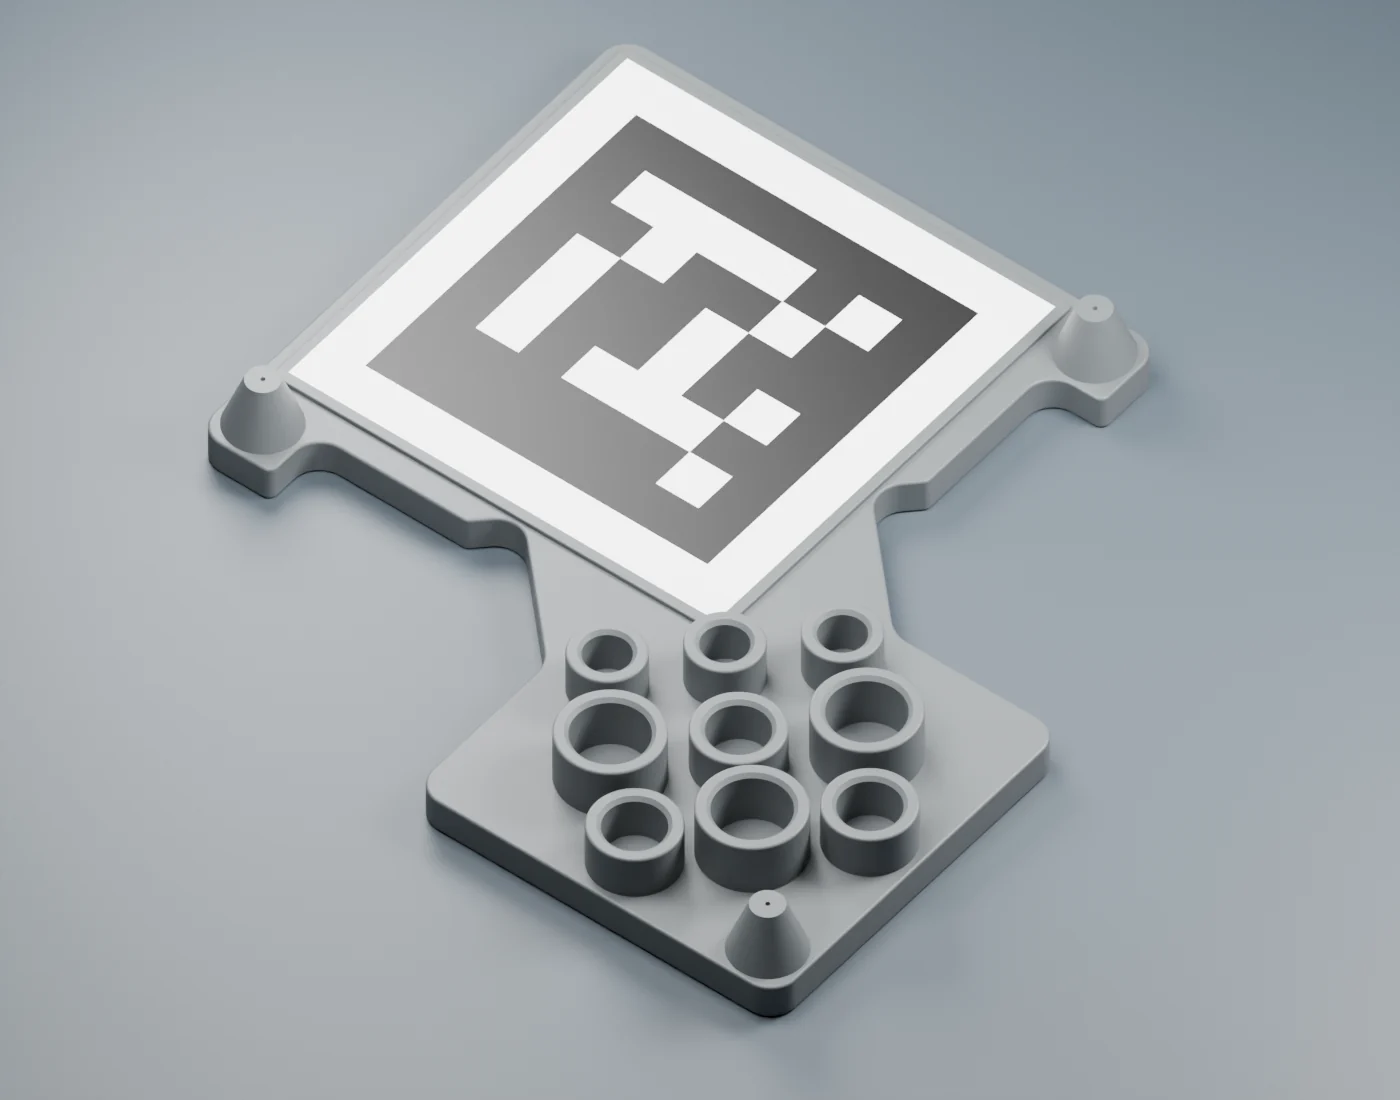
v2
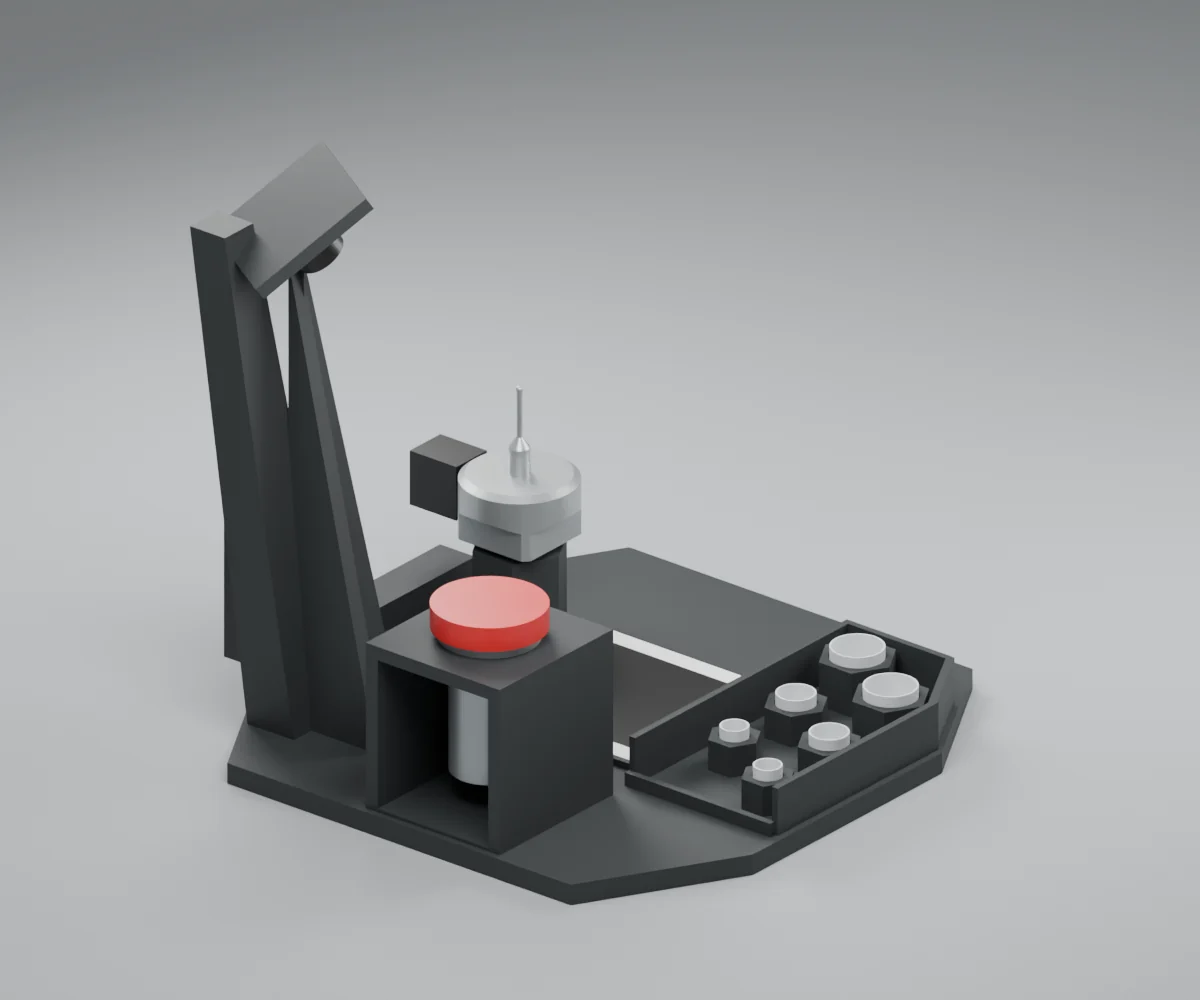
v3
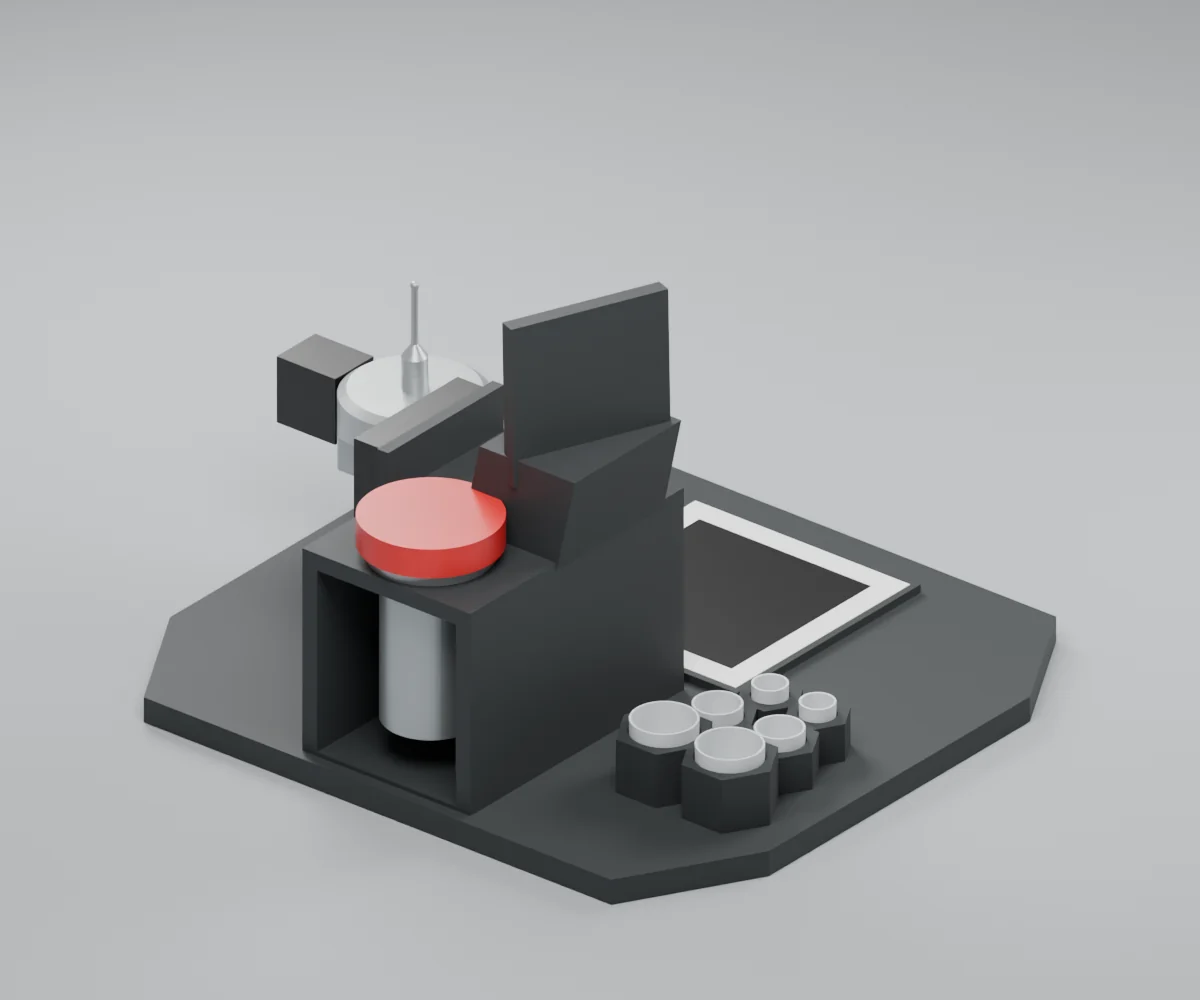
v4
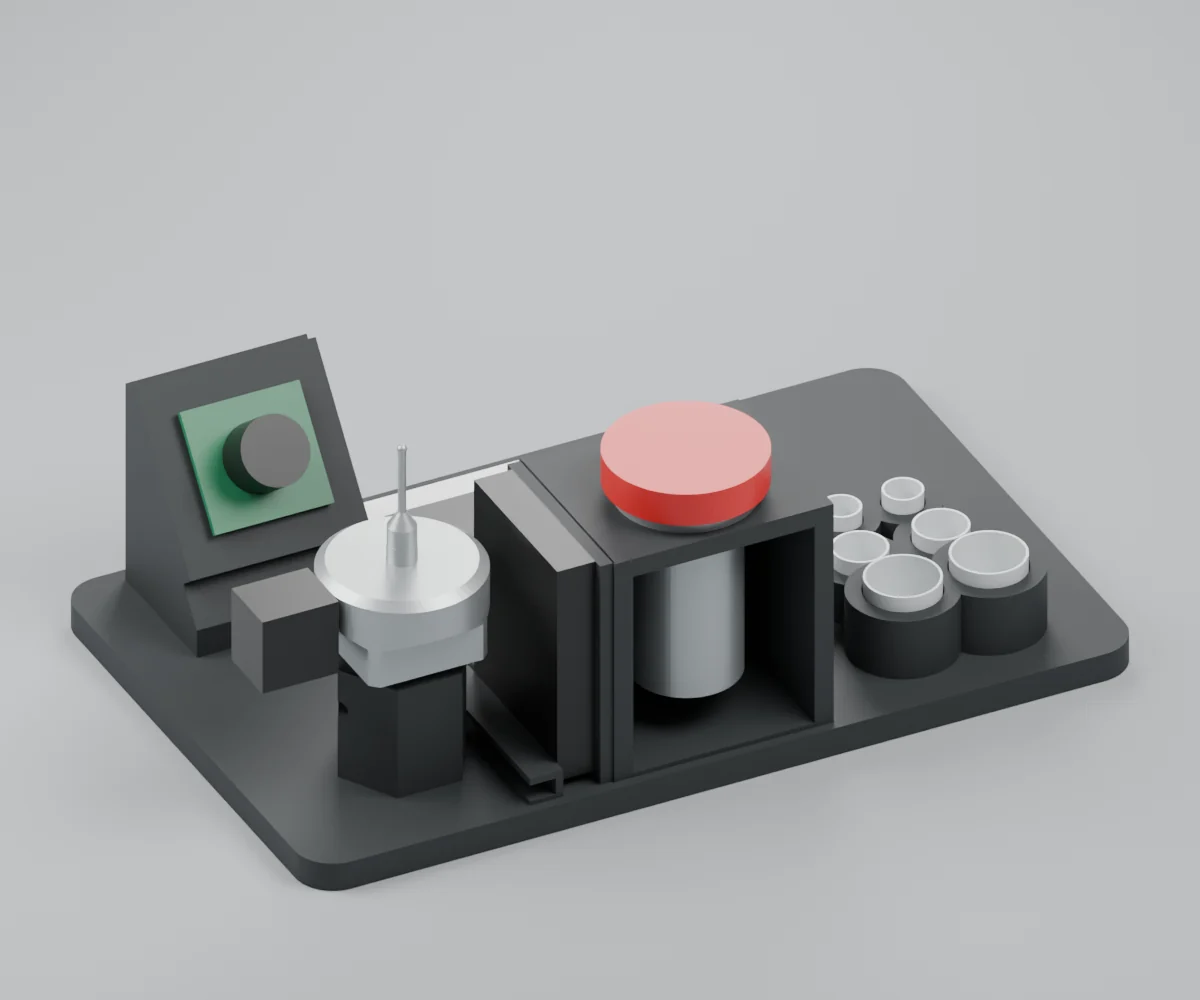
v5
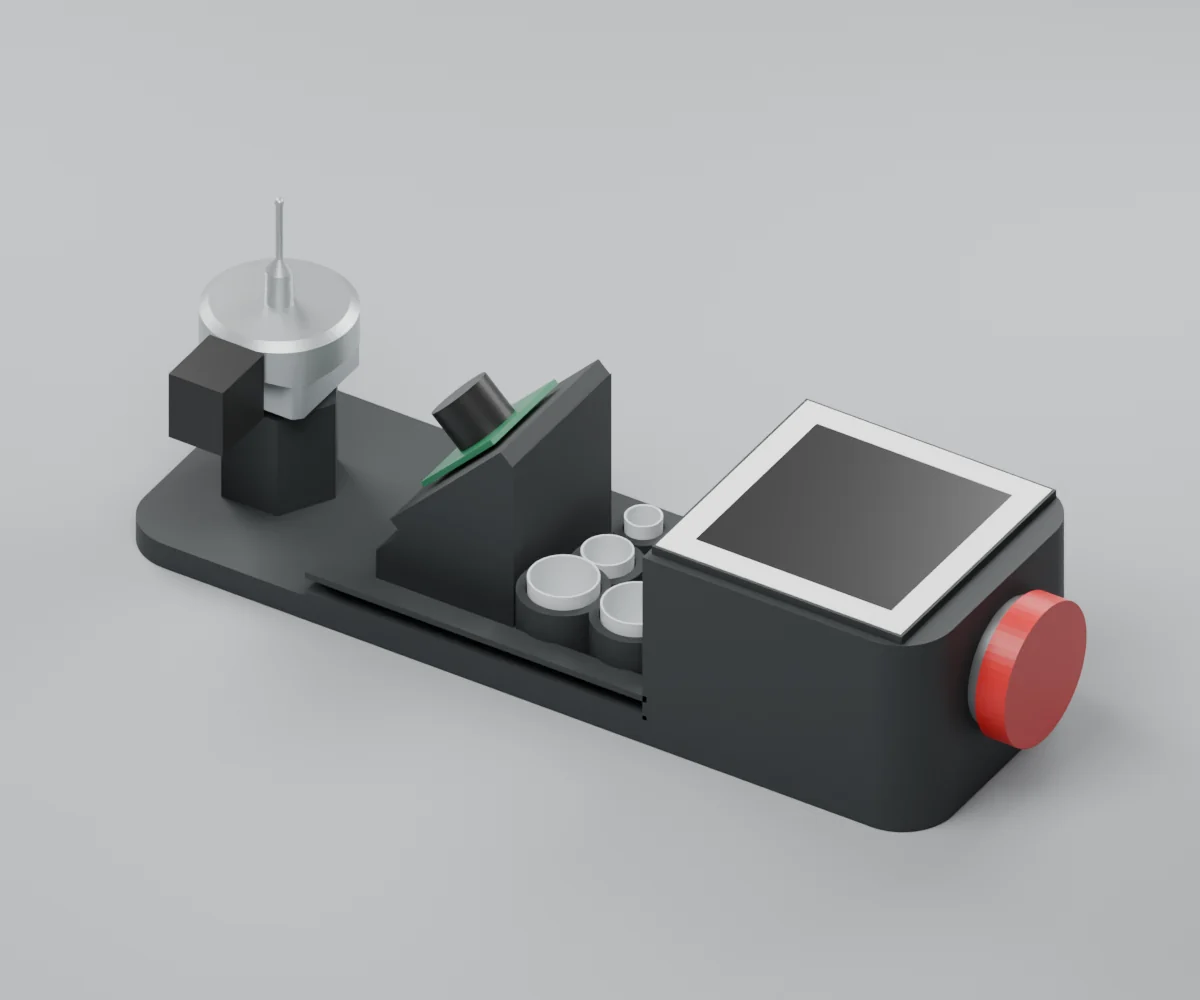
v6
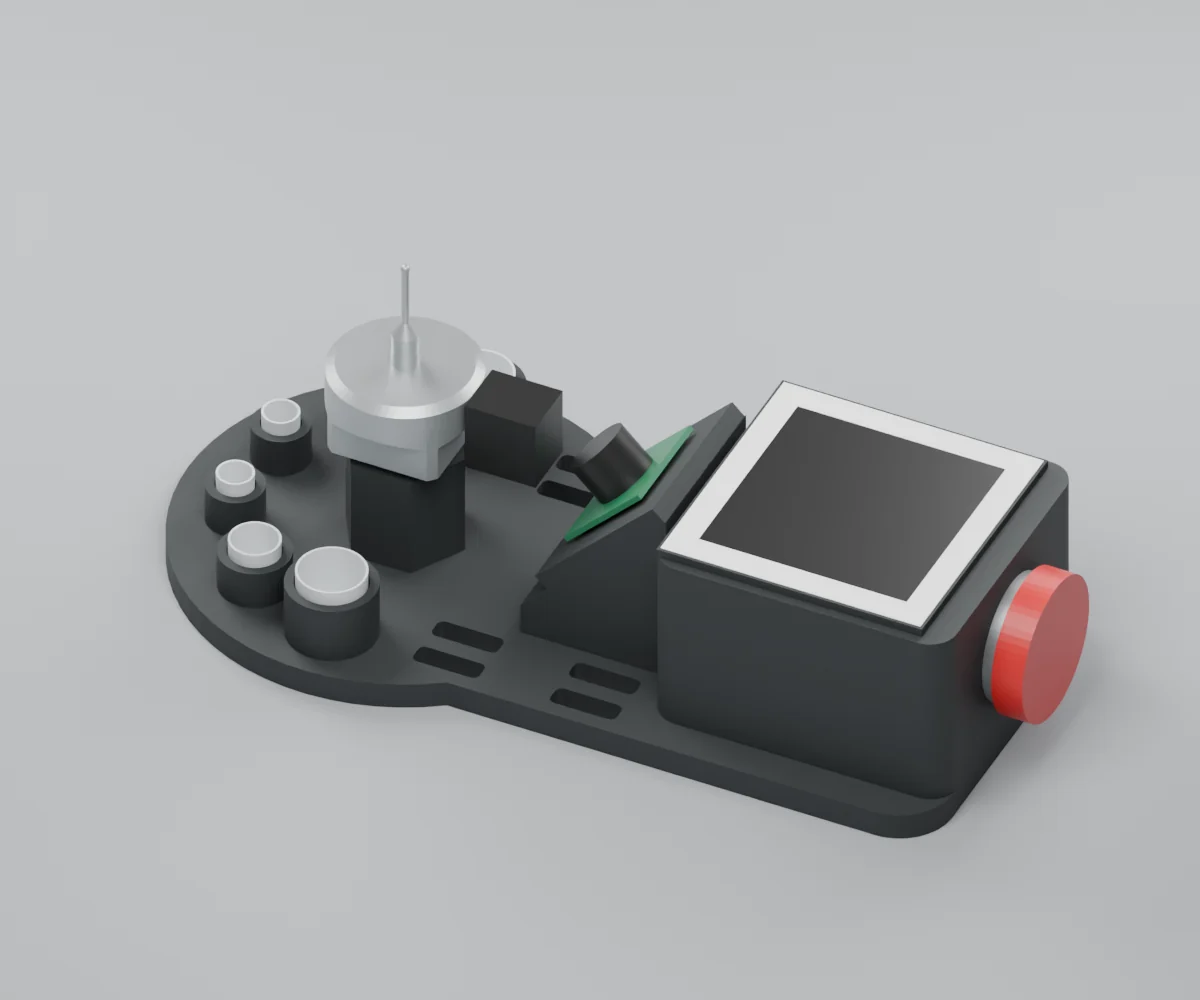
v7
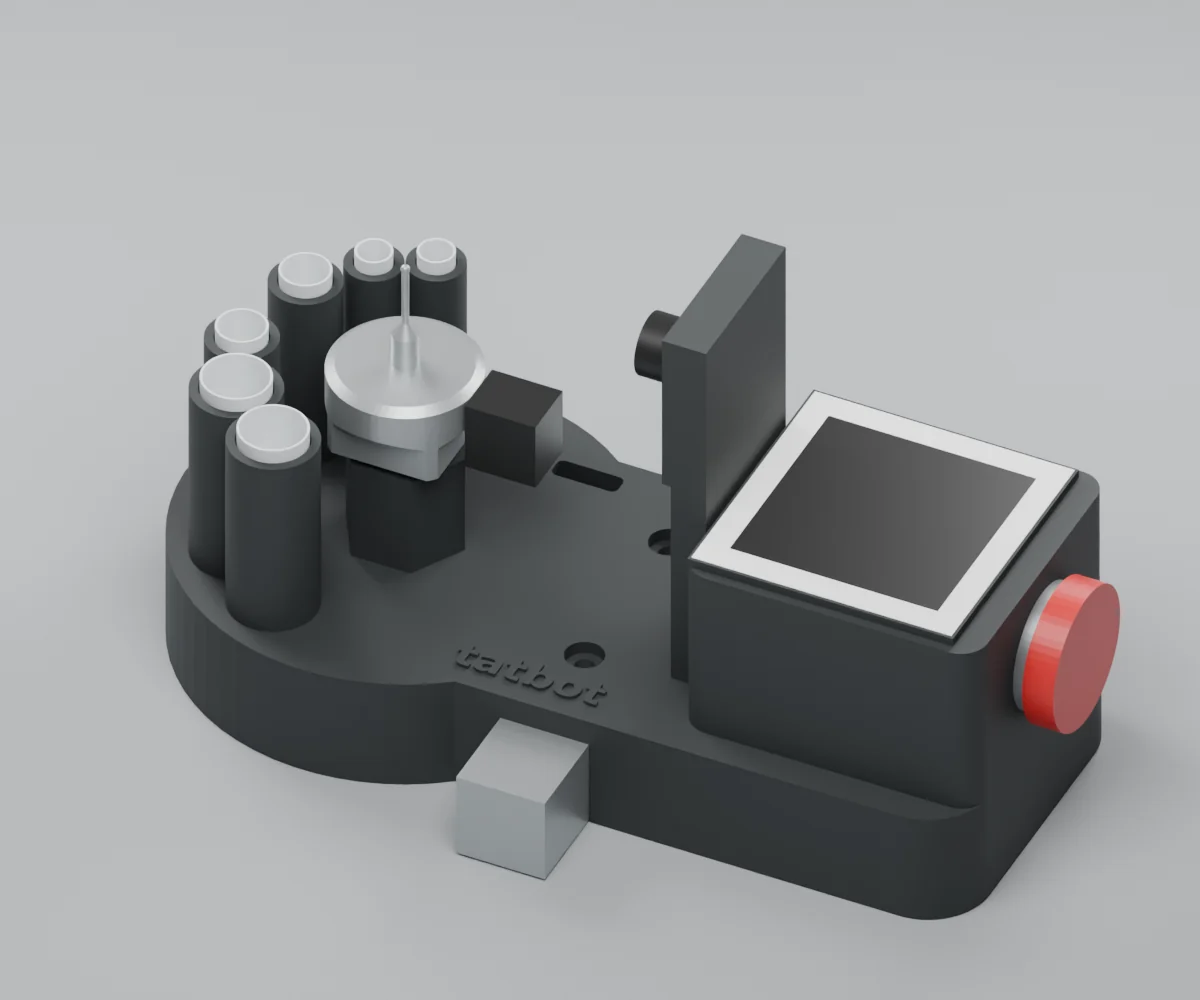
v8
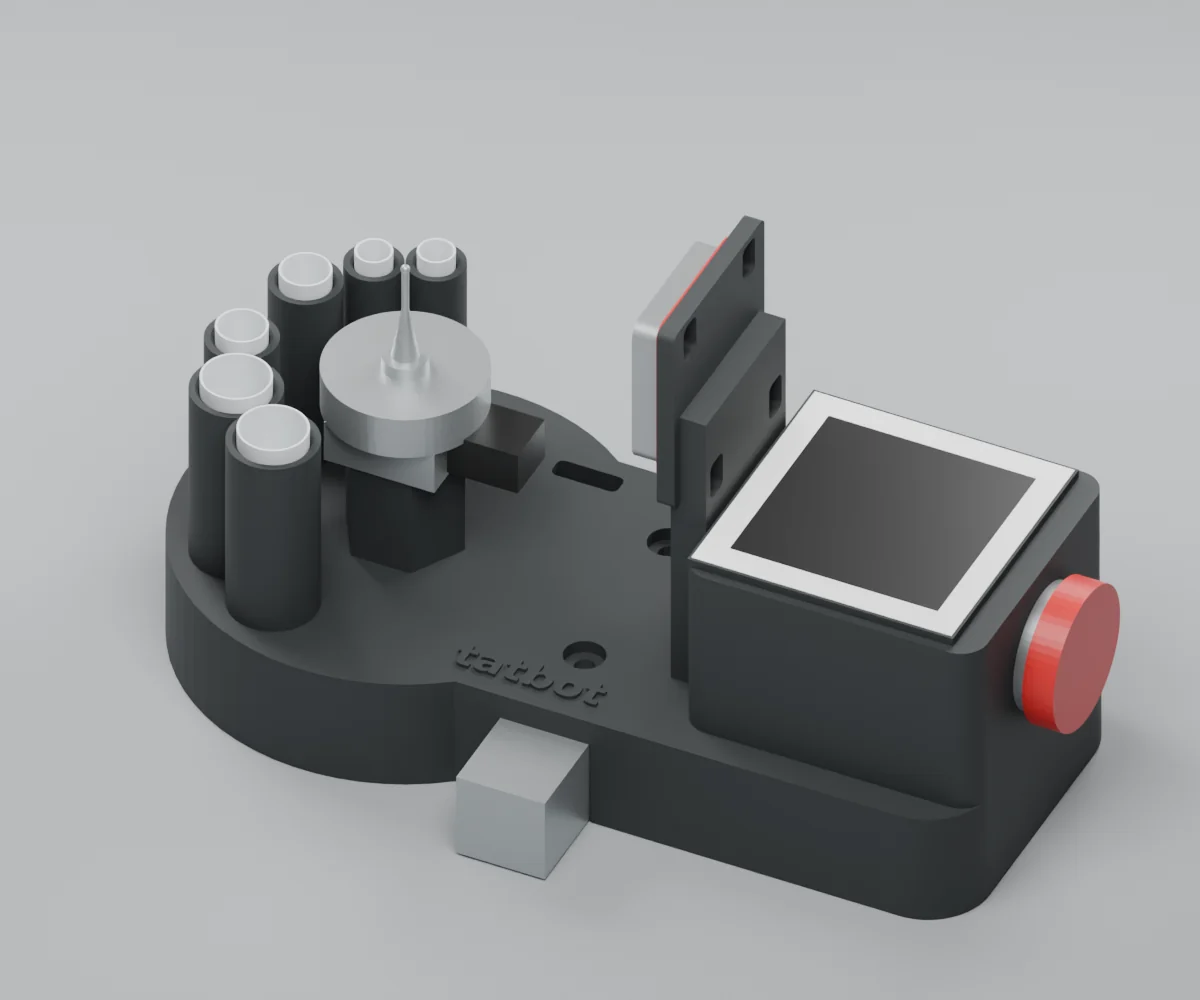
v9
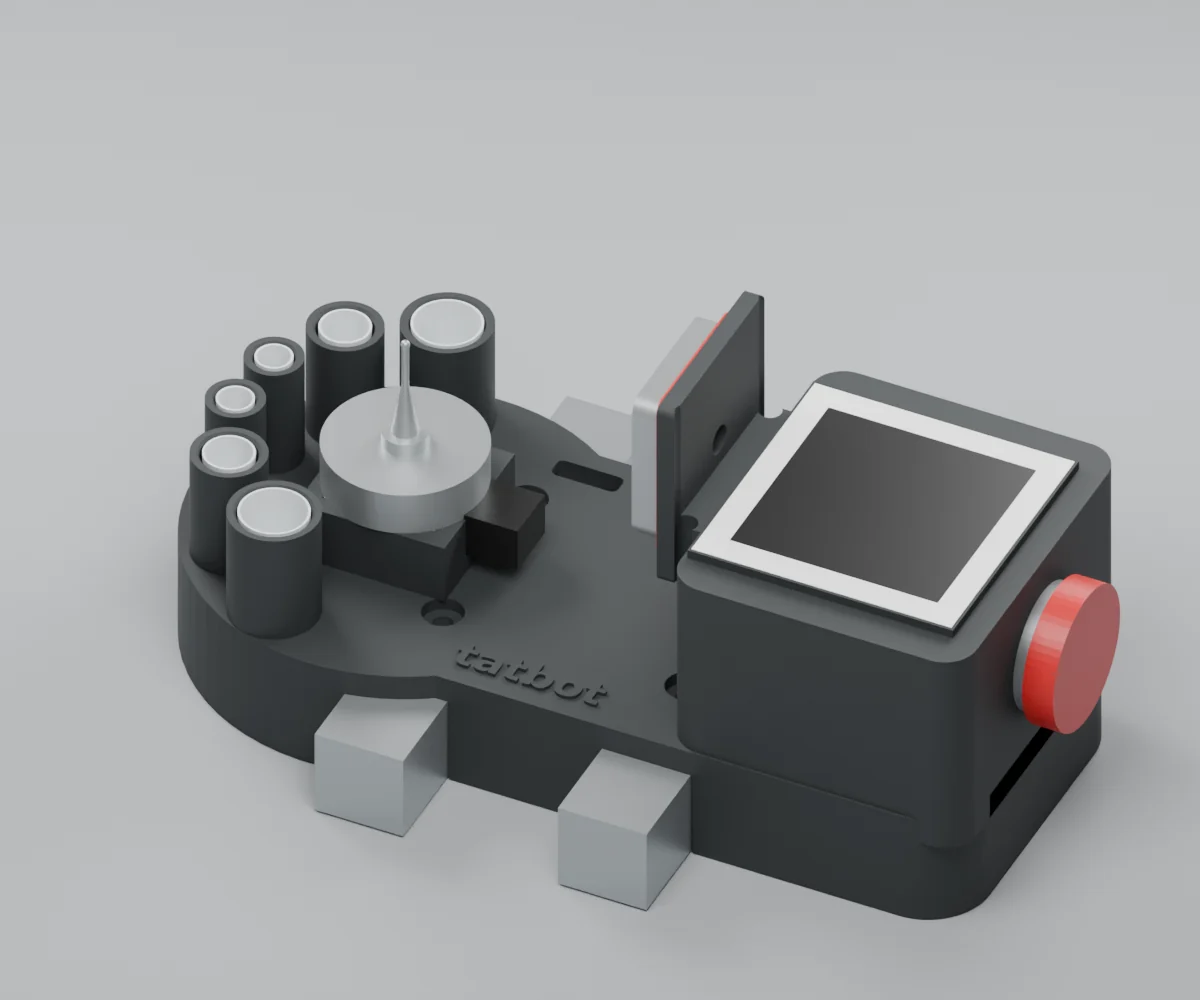
v10
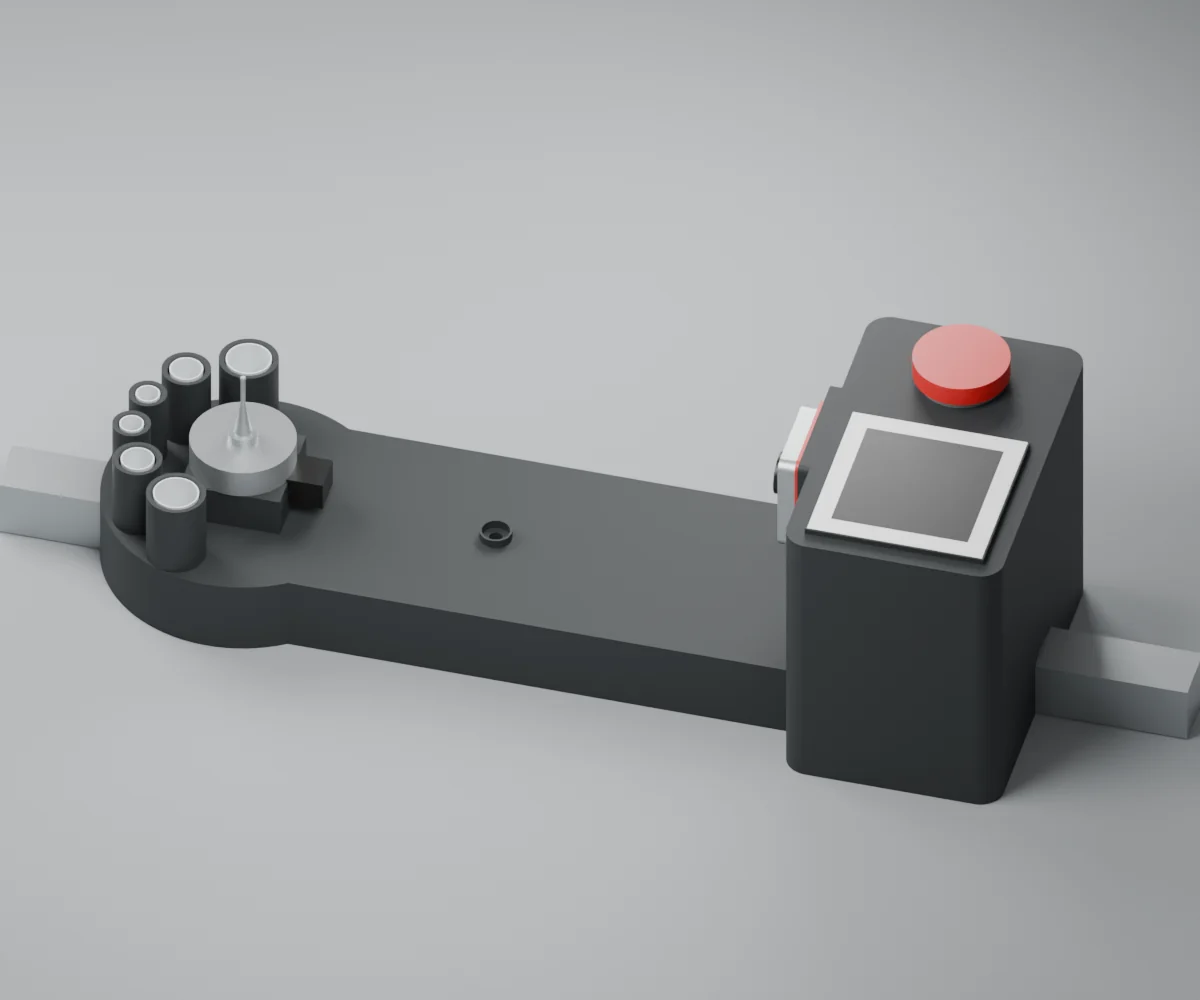
v11
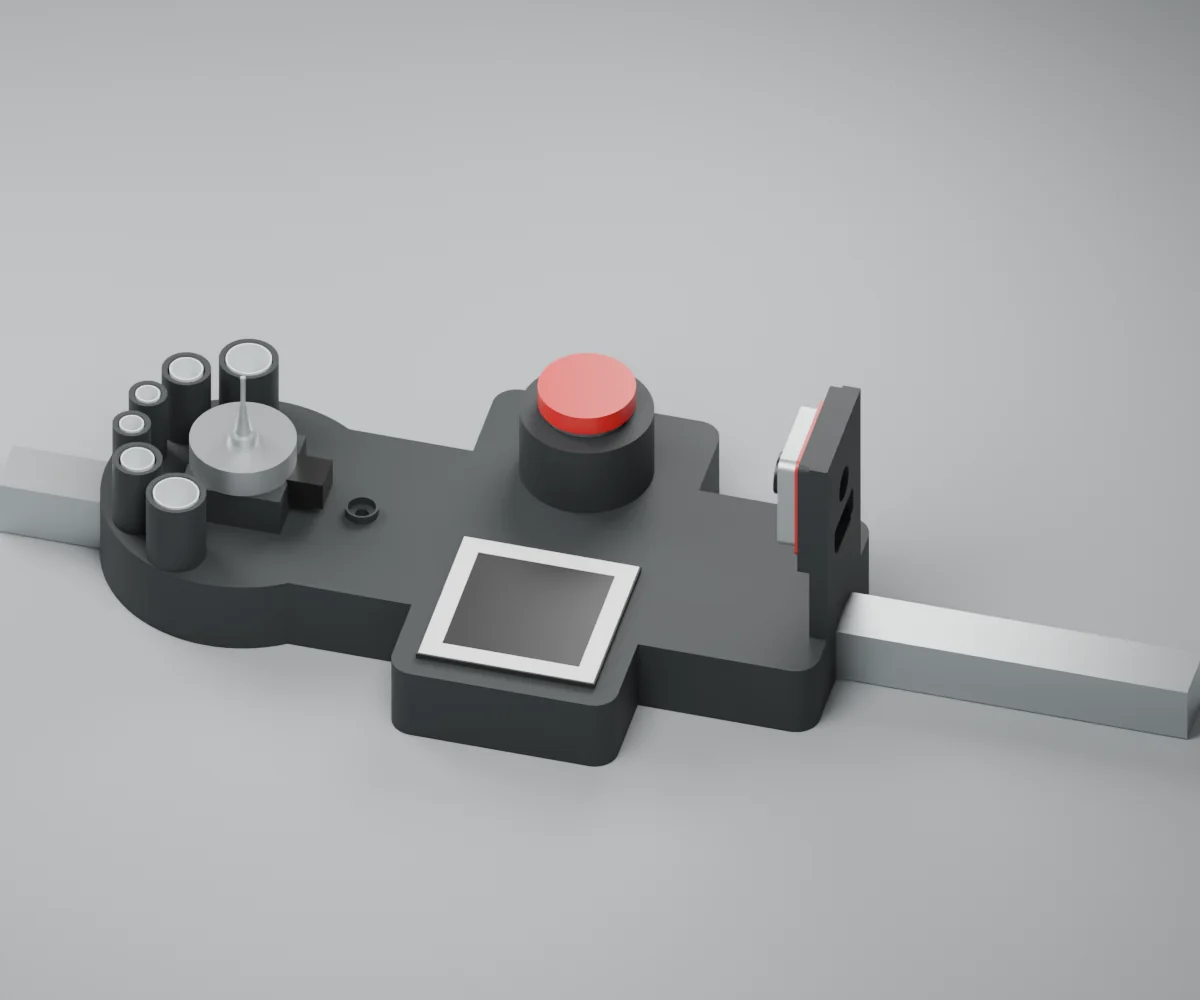
v12
Deep Visuomotor Policies
Images + Robot Configuration In, Motor Torques Out
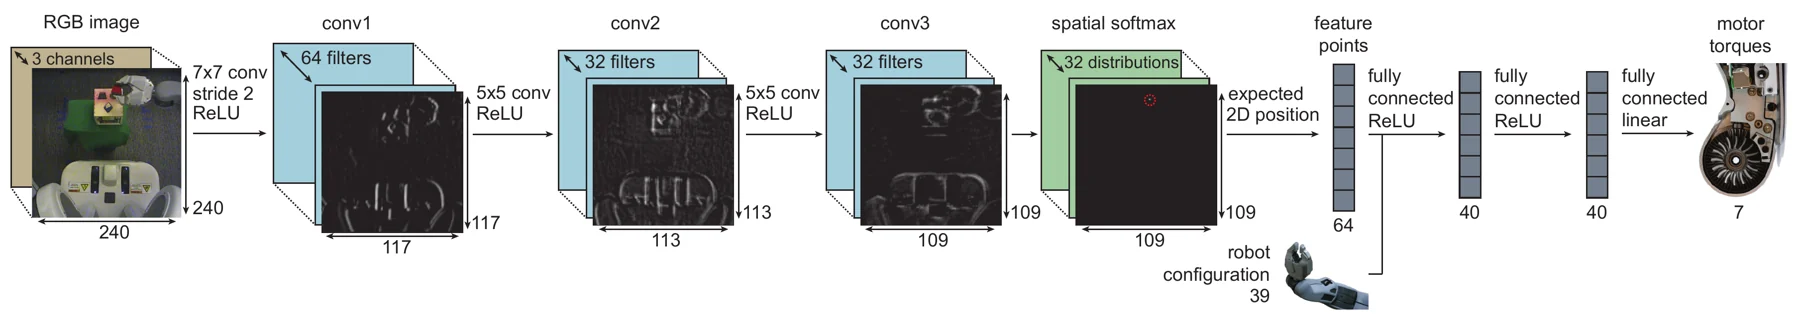
Research example · see original source for evaluation conditions.
Agents Controlling Robots
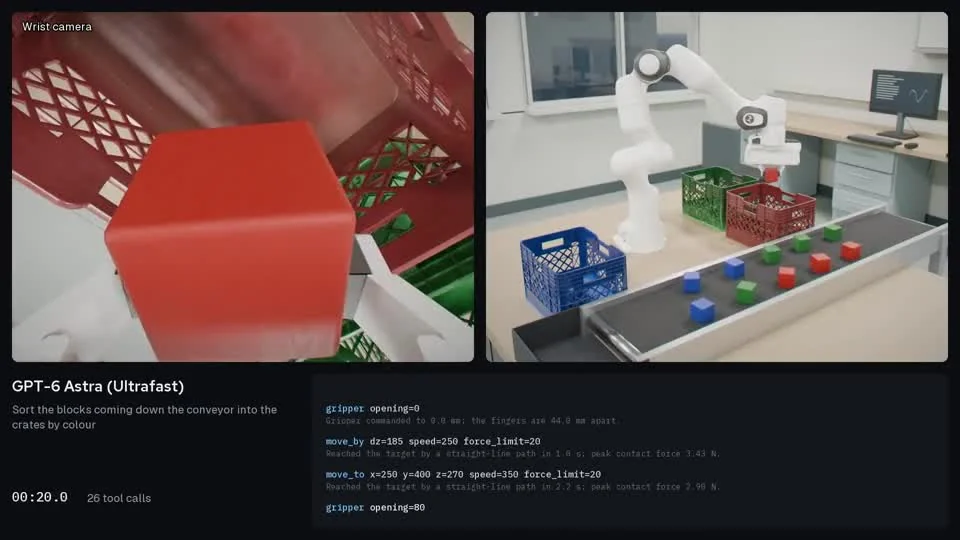 ▶ Watch original
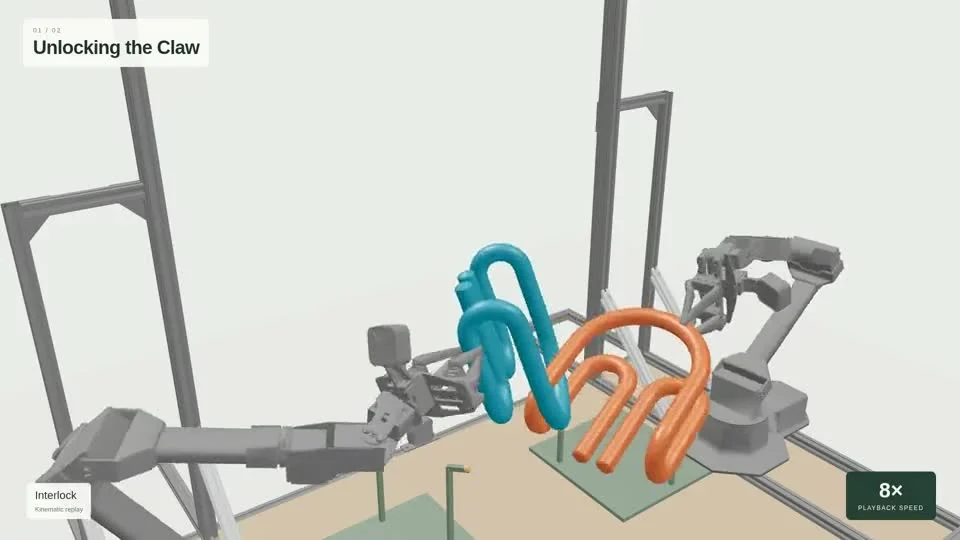 ▶ Watch original
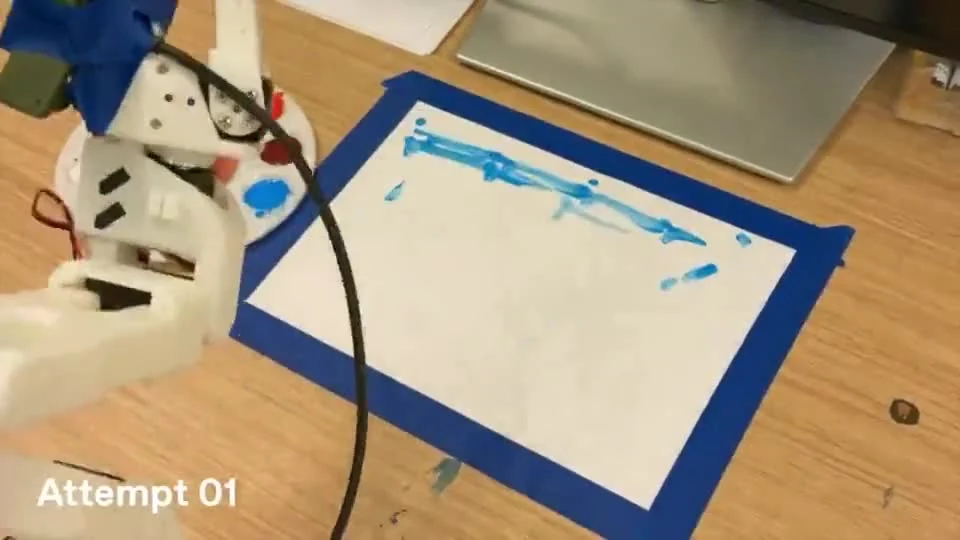 ▶ Watch original
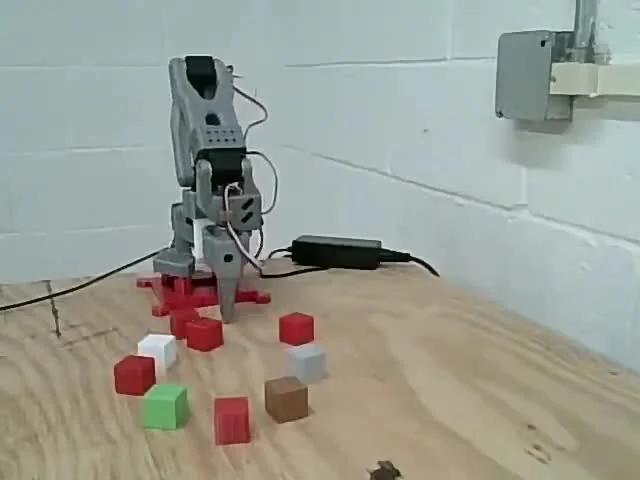 ▶ Watch original
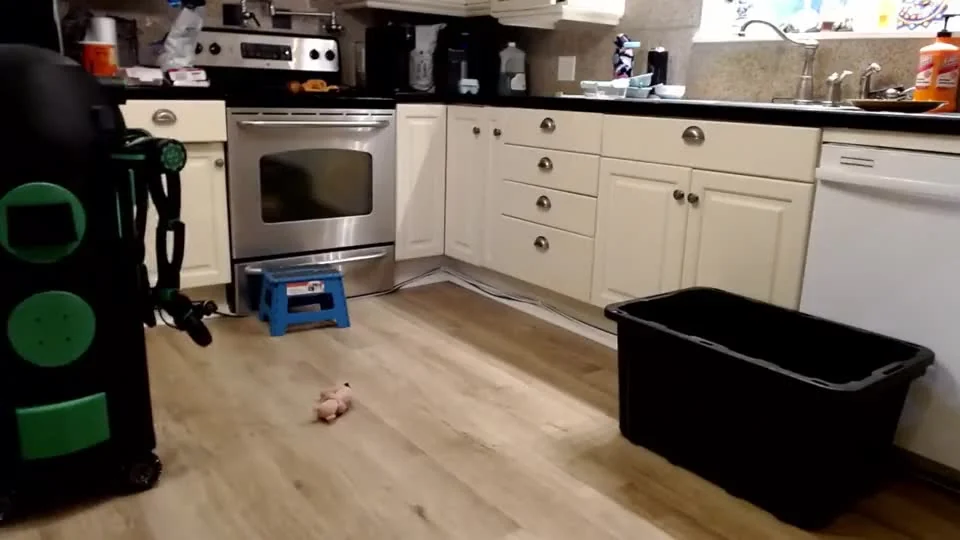 ▶ Watch original
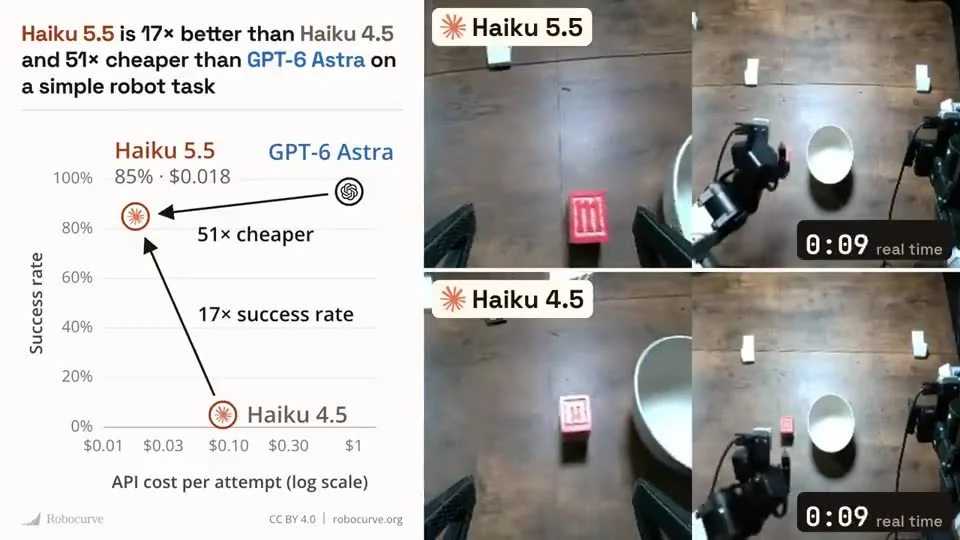 ▶ Watch original
Research example · see original source for evaluation conditions.
The Bitter Lesson Comes to Robotics
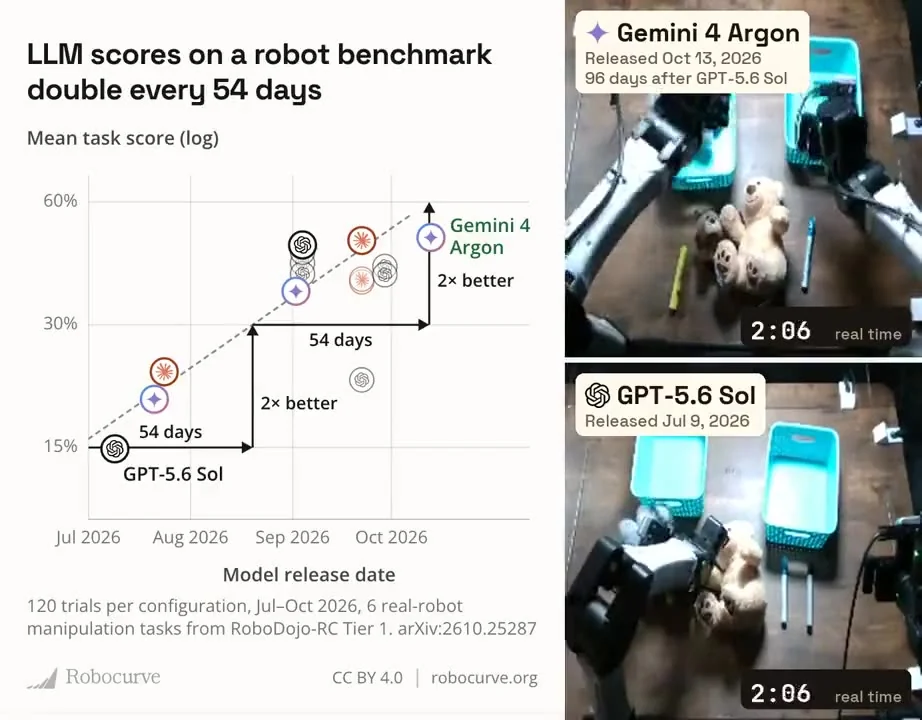 ▶ Watch original
Research example · see original source for evaluation conditions.
Computer Use
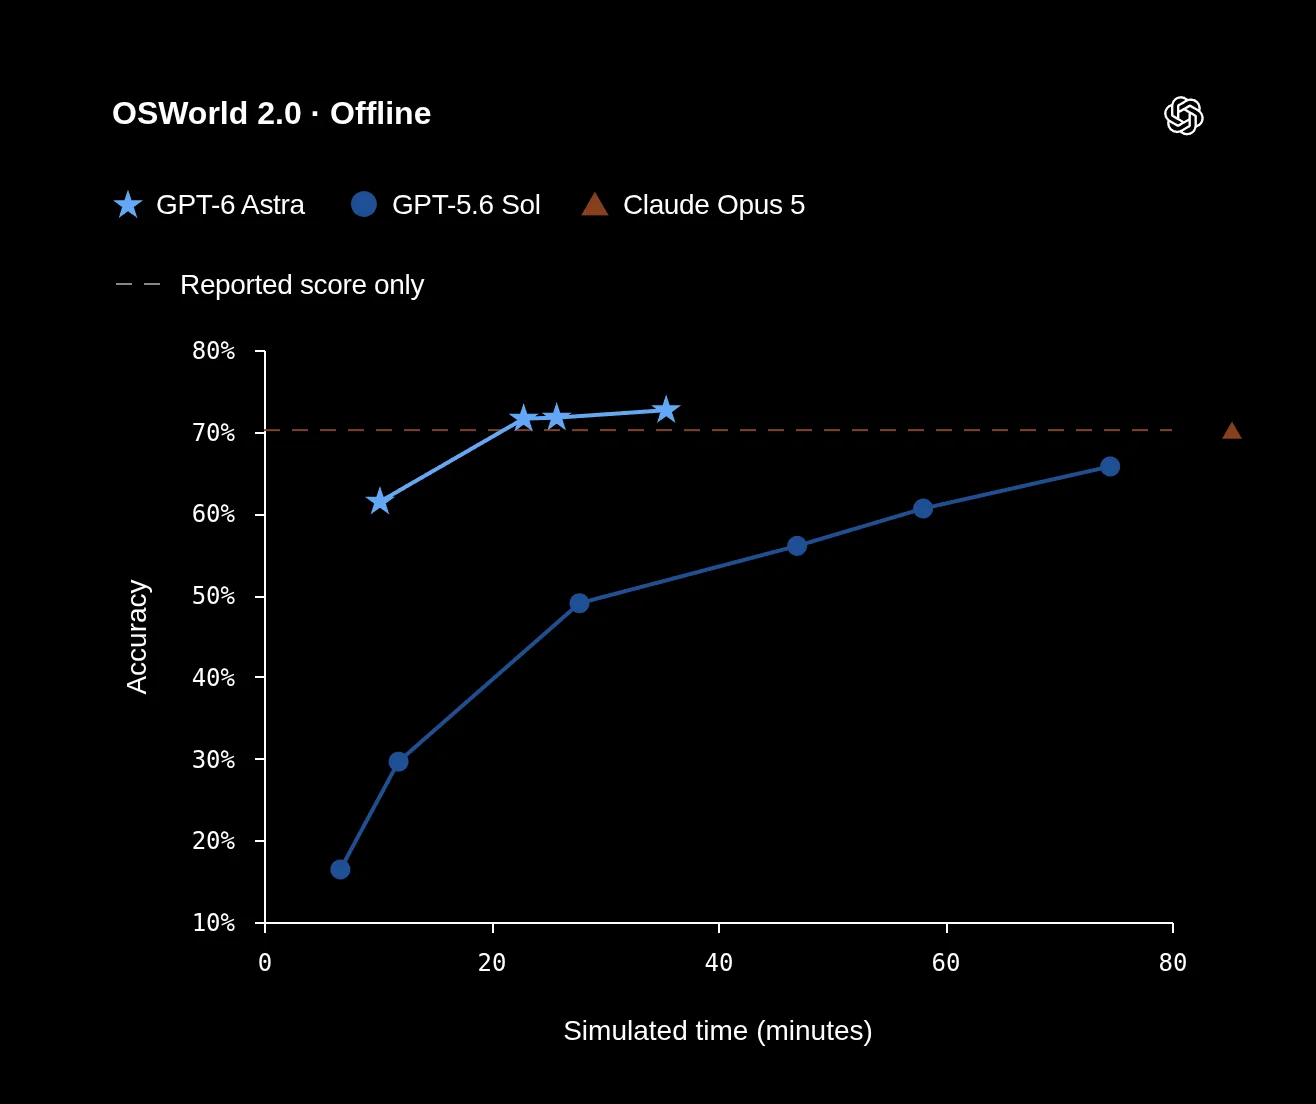
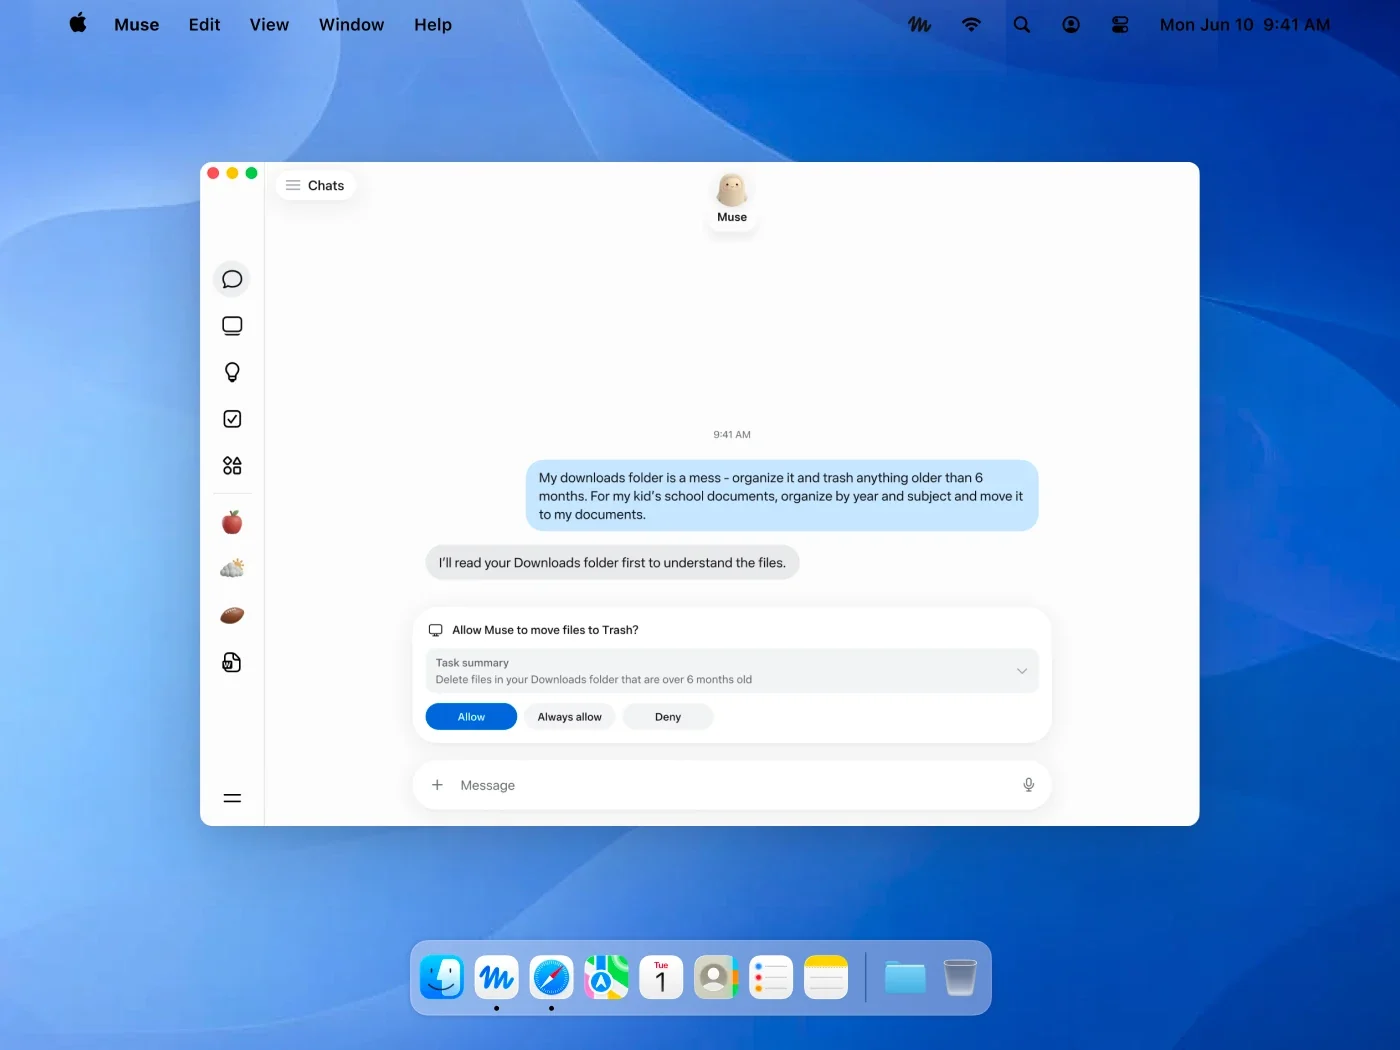
OSWorld: partial task score, simulated time
Research example · see original source for evaluation conditions.
Thinking, Fast and Slow
System 1
“operates automatically and quickly, with little or no effort…”
System 2
“allocates attention to the effortful mental activities that demand it…”
Daniel Kahneman, 2011
Short excerpts from Chapter 1
Research example · see original source for evaluation conditions.
System 1 + System 2 Inside a VLA
GR00T N1 (NVIDIA, 2025)
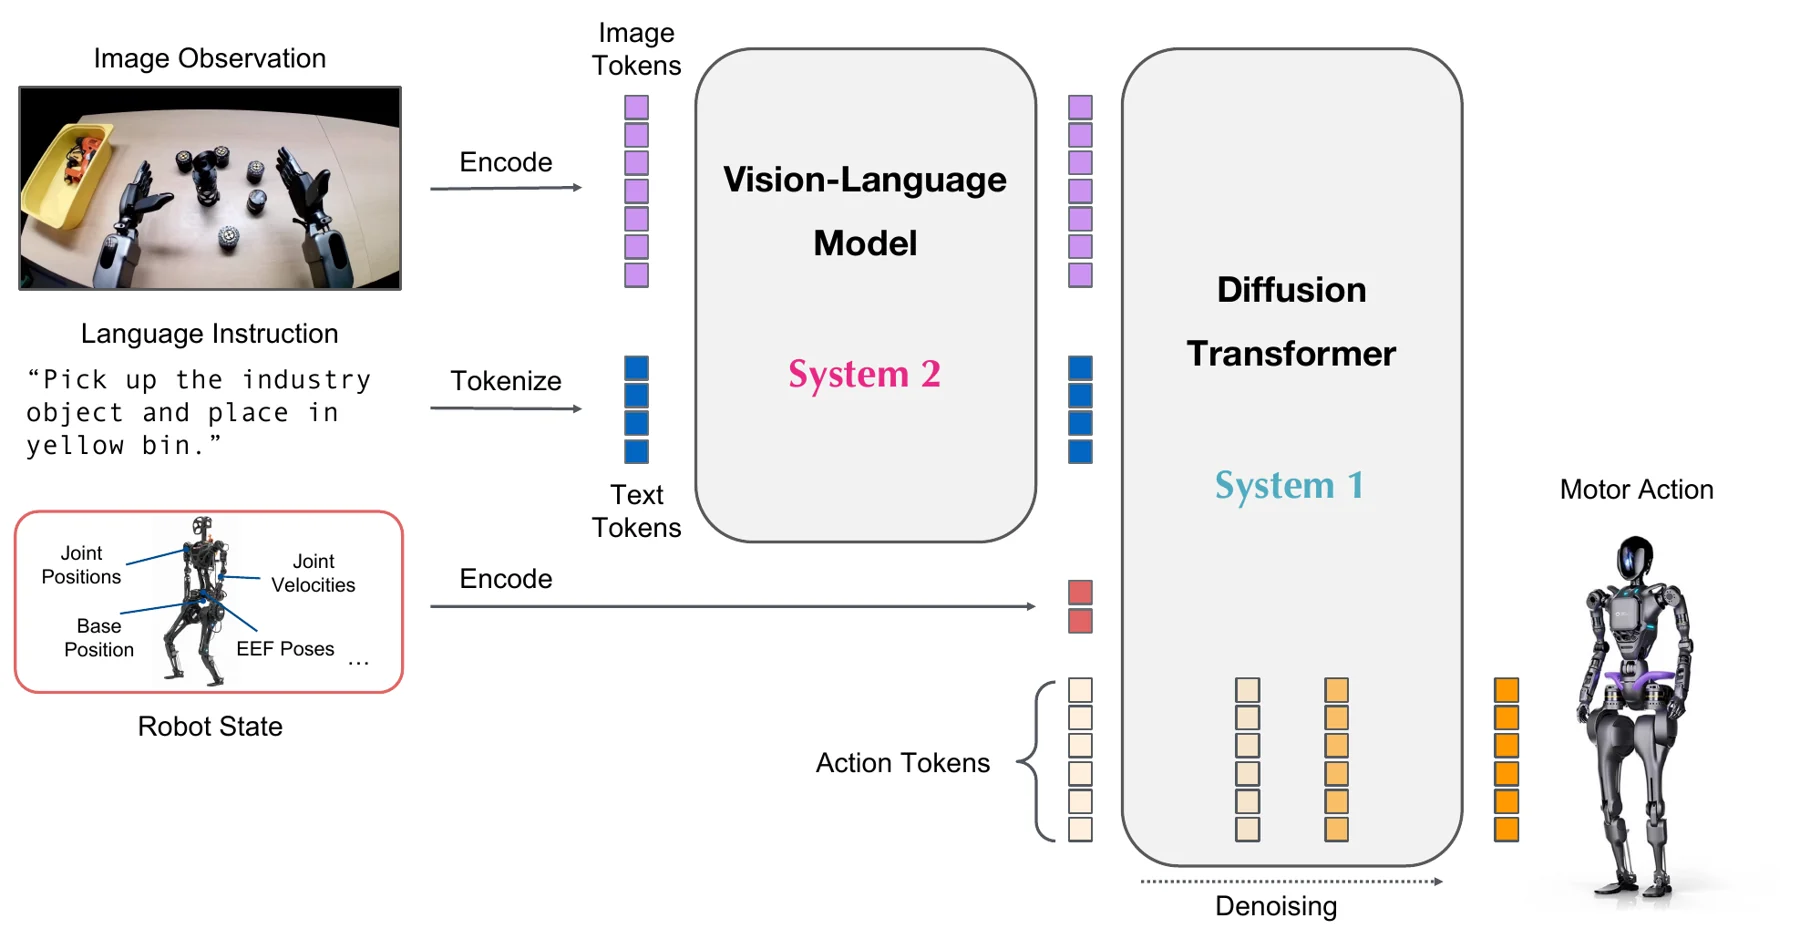
Research example · see original source for evaluation conditions.
System 1 + System 2: Agent + VLA
System 2
System 1
Agent
Subtask
Observation
VLA
GR00T N1.6
Robot actions
Codex
Research example · see original source for evaluation conditions.
FLUX 3 Action
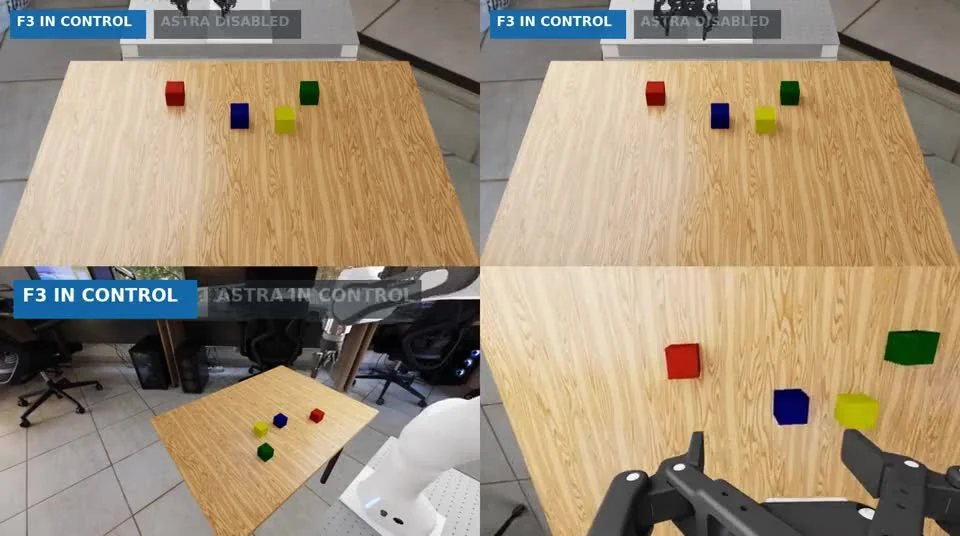 ▶ Watch original
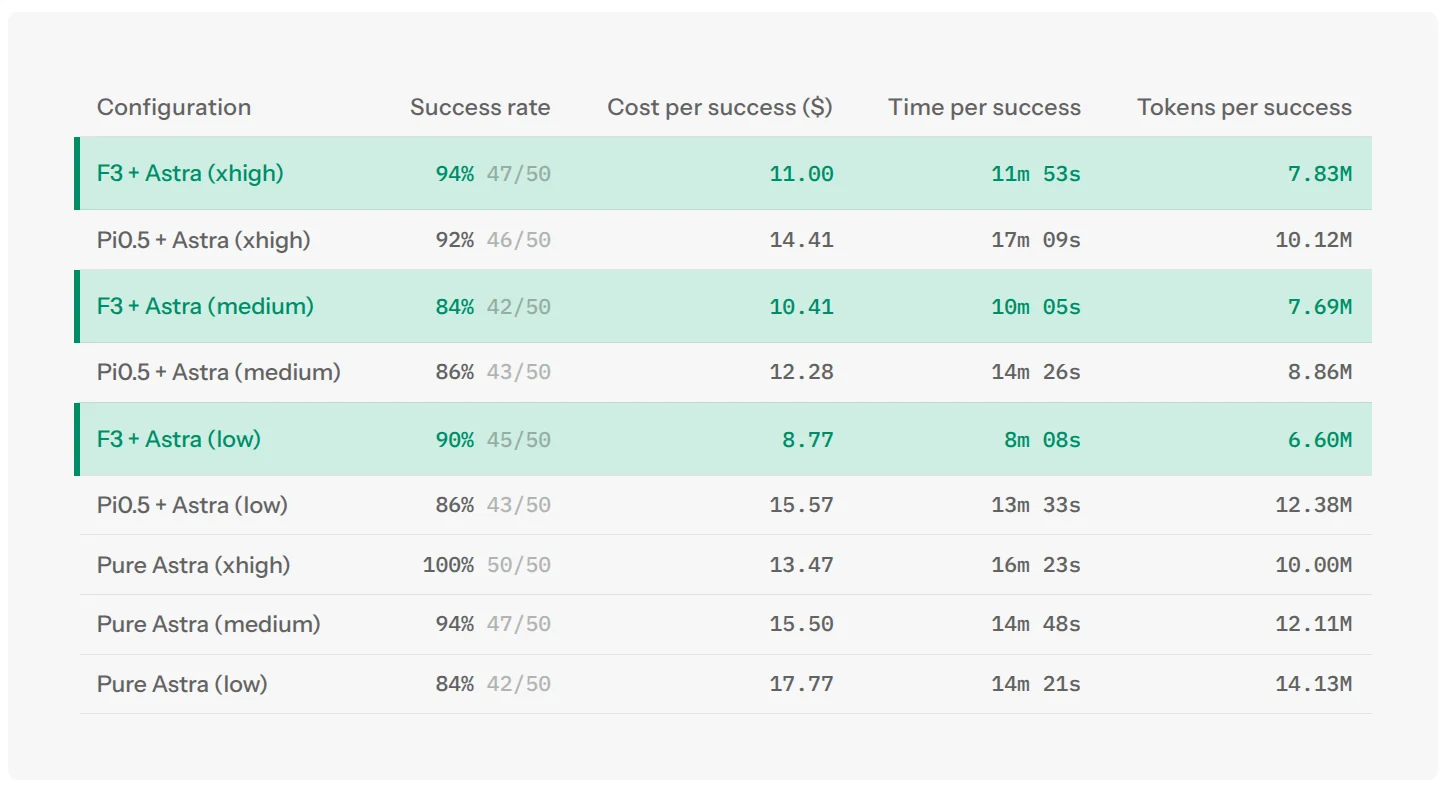
Research example · see original source for evaluation conditions.
ASPIRE: Success vs. Cost
10 LIBERO-Pro tasks · held-out success vs. estimated API cost
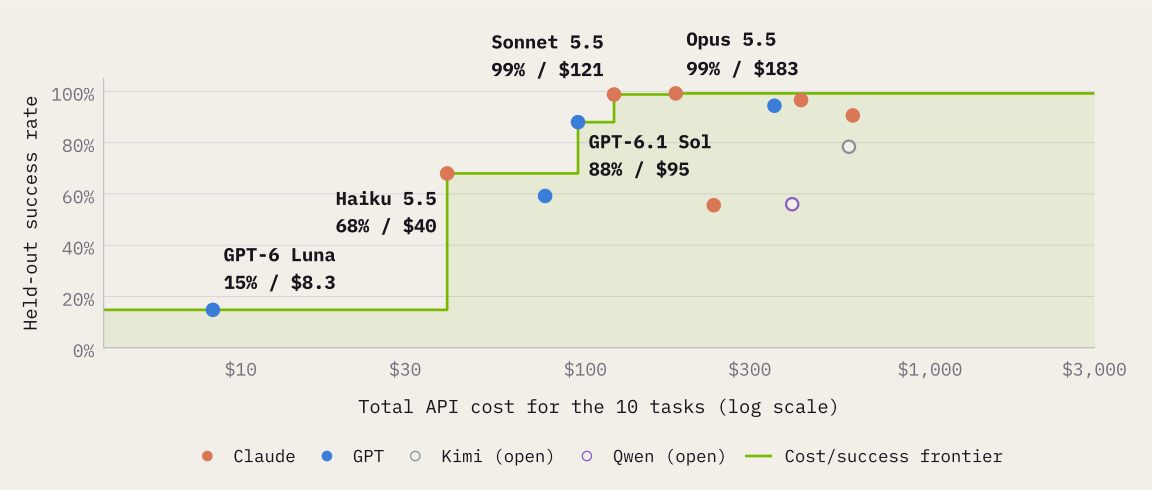
Research example · see original source for evaluation conditions.
ASPIRE: Learning on a Real Robot
Rubik’s Cube · tokens and time per completed face turn
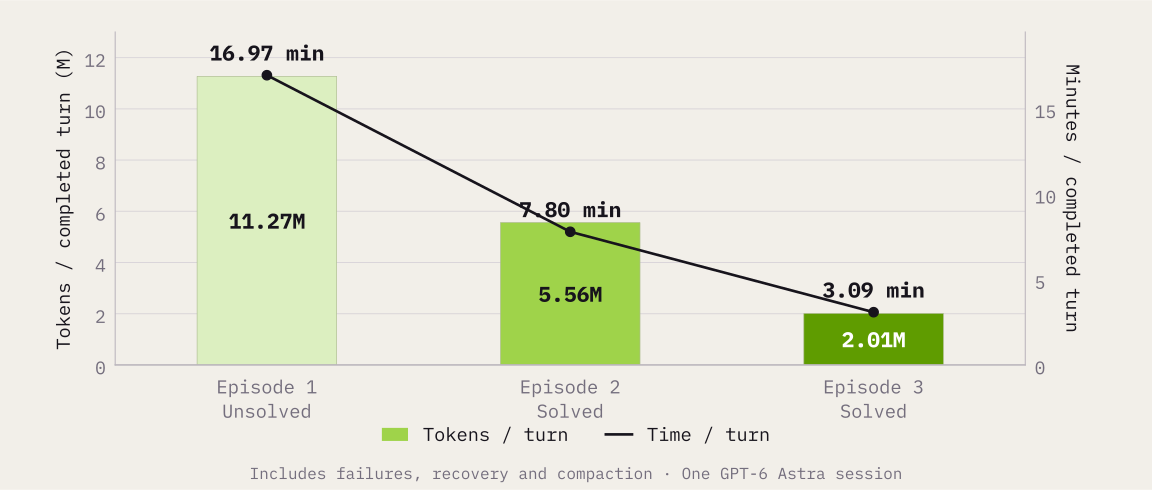
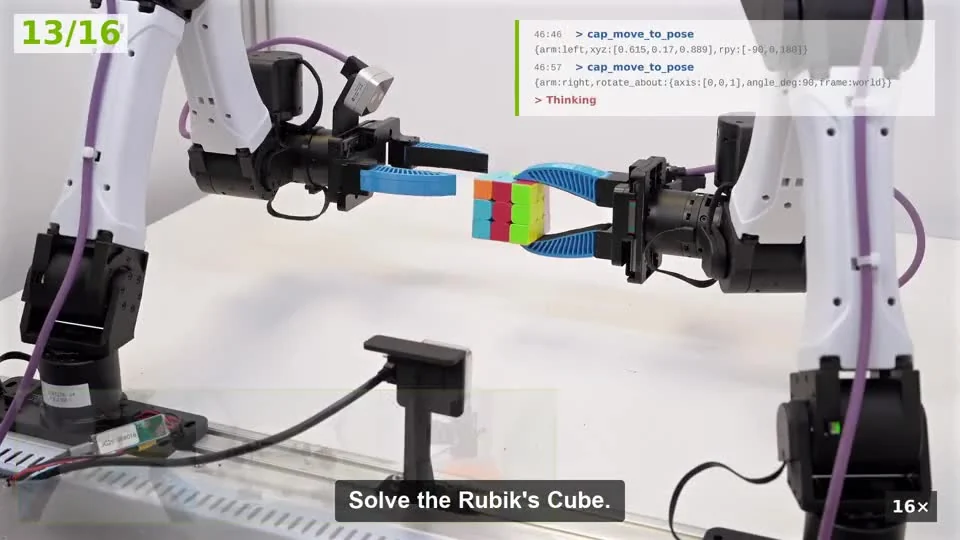 ▶ Watch original
Example cube turns
Research example · see original source for evaluation conditions.
ENPIRE Architecture
Agentic Robot Policy Self-Improvement in the Real World
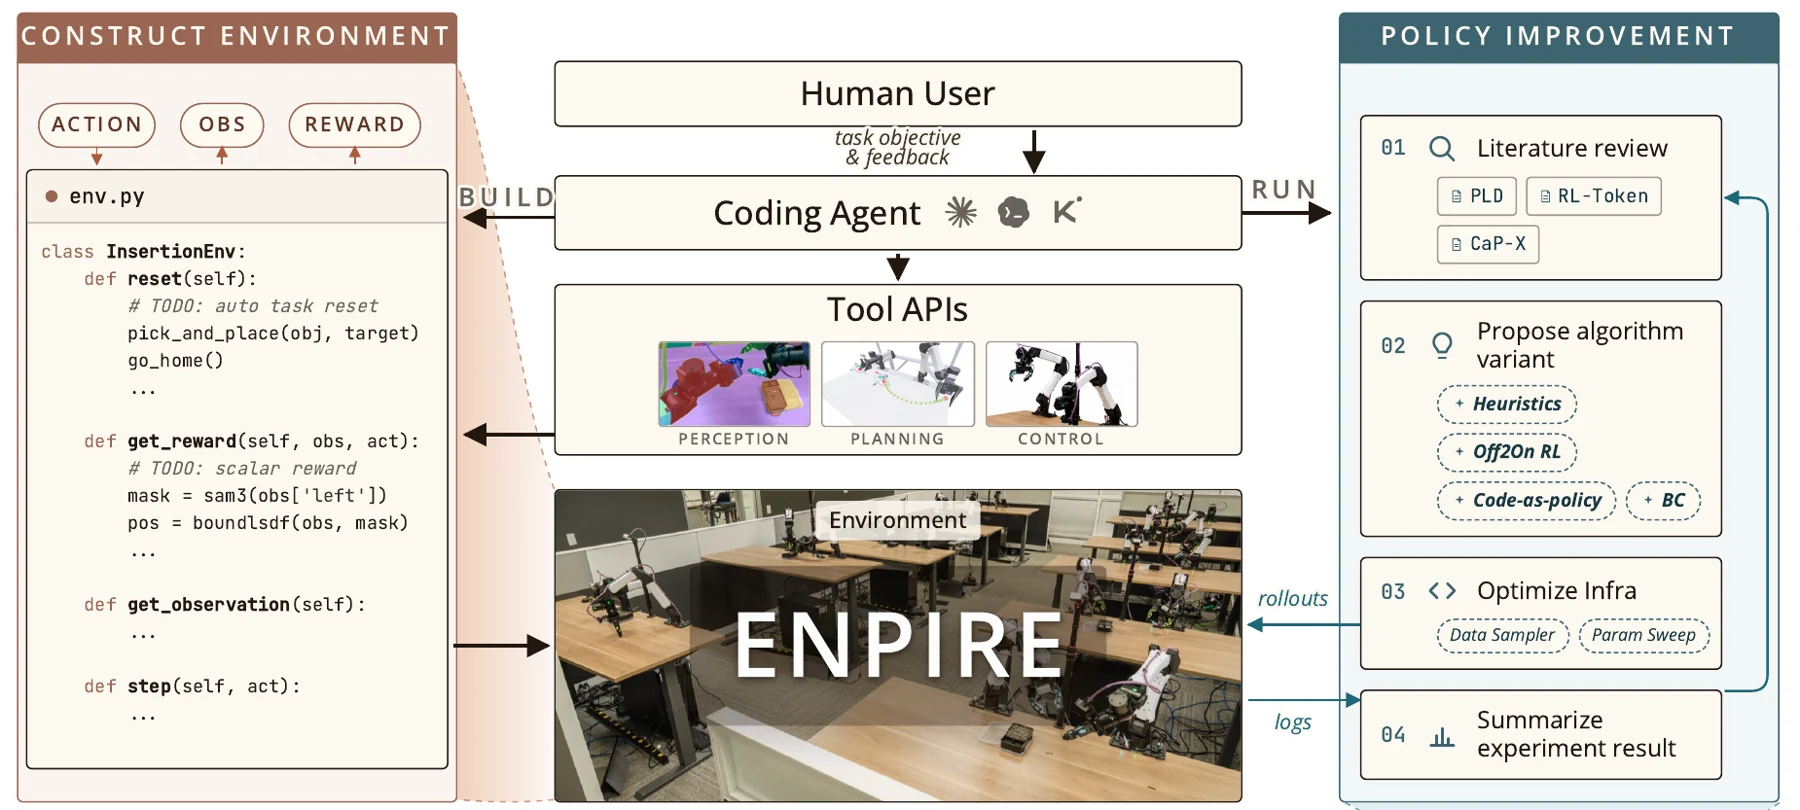
Research example · see original source for evaluation conditions.
MRU: Mean Robot Utilization
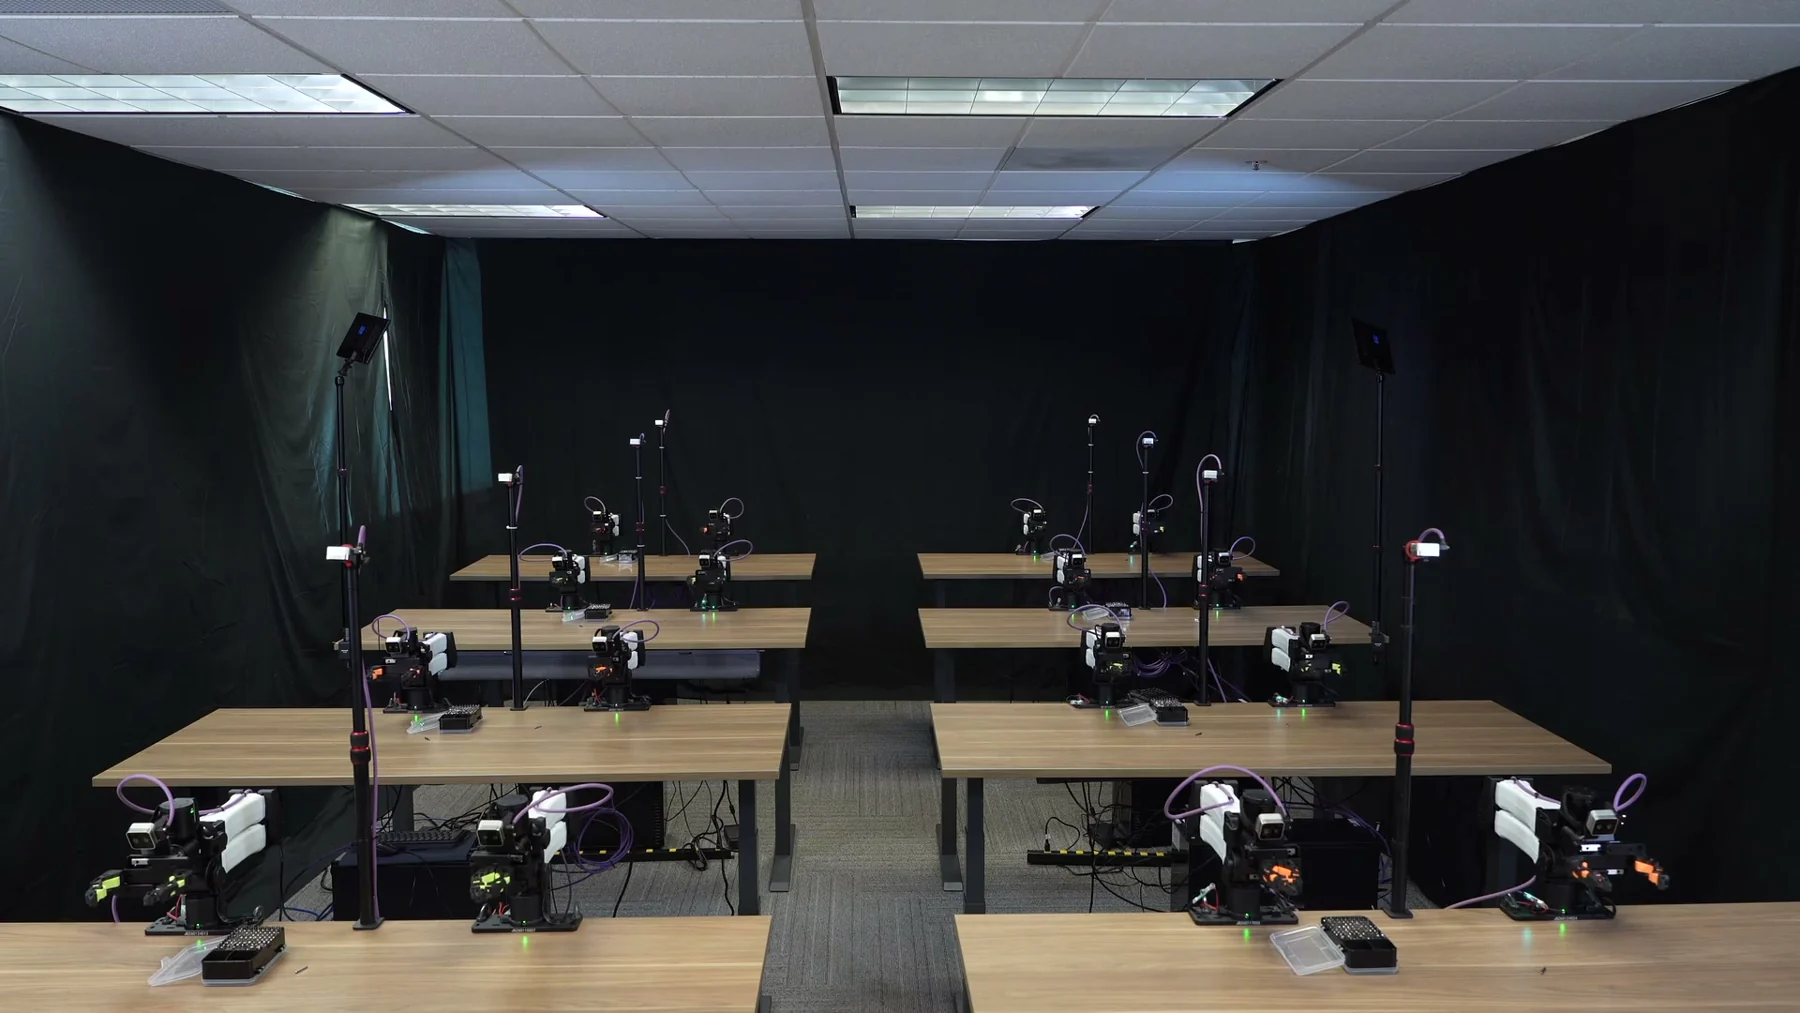 ▶ Watch original
Research example · see original source for evaluation conditions.
Tatbot: A System 3 Architecture


CLOUD MODELS
LOCAL · ON SITE
System 3
System 2
System 1
Server racks
DGX Spark
Jetson Thor
Opus 5.5
GPT-6.1 Sol
Qwen
Python
Rust
Improve
Execute
Logs + outcomes
LeRobot
Conceptual architecture · research direction, not a verified deployment.
Thank You